WD DRIVE
We believe good motion control
is meant to be open, approachable, and ready to drive every sector forward.
WD DRIVE is a young desktop motion control team. Three product lines and two protocol ecosystems, optimized for 3D printers and PNP(pick-and-place) machines.
01 Who We Are
Our Product Positioning
We are not a workshop that "can make any motor" — we are a team focused on doing things thoroughly. Our founders come from the motion control and open-source hardware communities. We've seen too many desktop machines turned away by "industrial-grade spec sheets": unaffordable and impractical.
So we position our products at the desktop consumer level: honest specs, fully open documentation, no locked-in protocols. Targeting markets like 3D printers and PNP(pick-and-place) machines, so that makers, studios and startups can use motors that just work.
Desktop-class ≠ watered-down specs — it means "affordable, understandable, and reachable" comes first.
02 Product Lines
Three Lines Currently on Sale
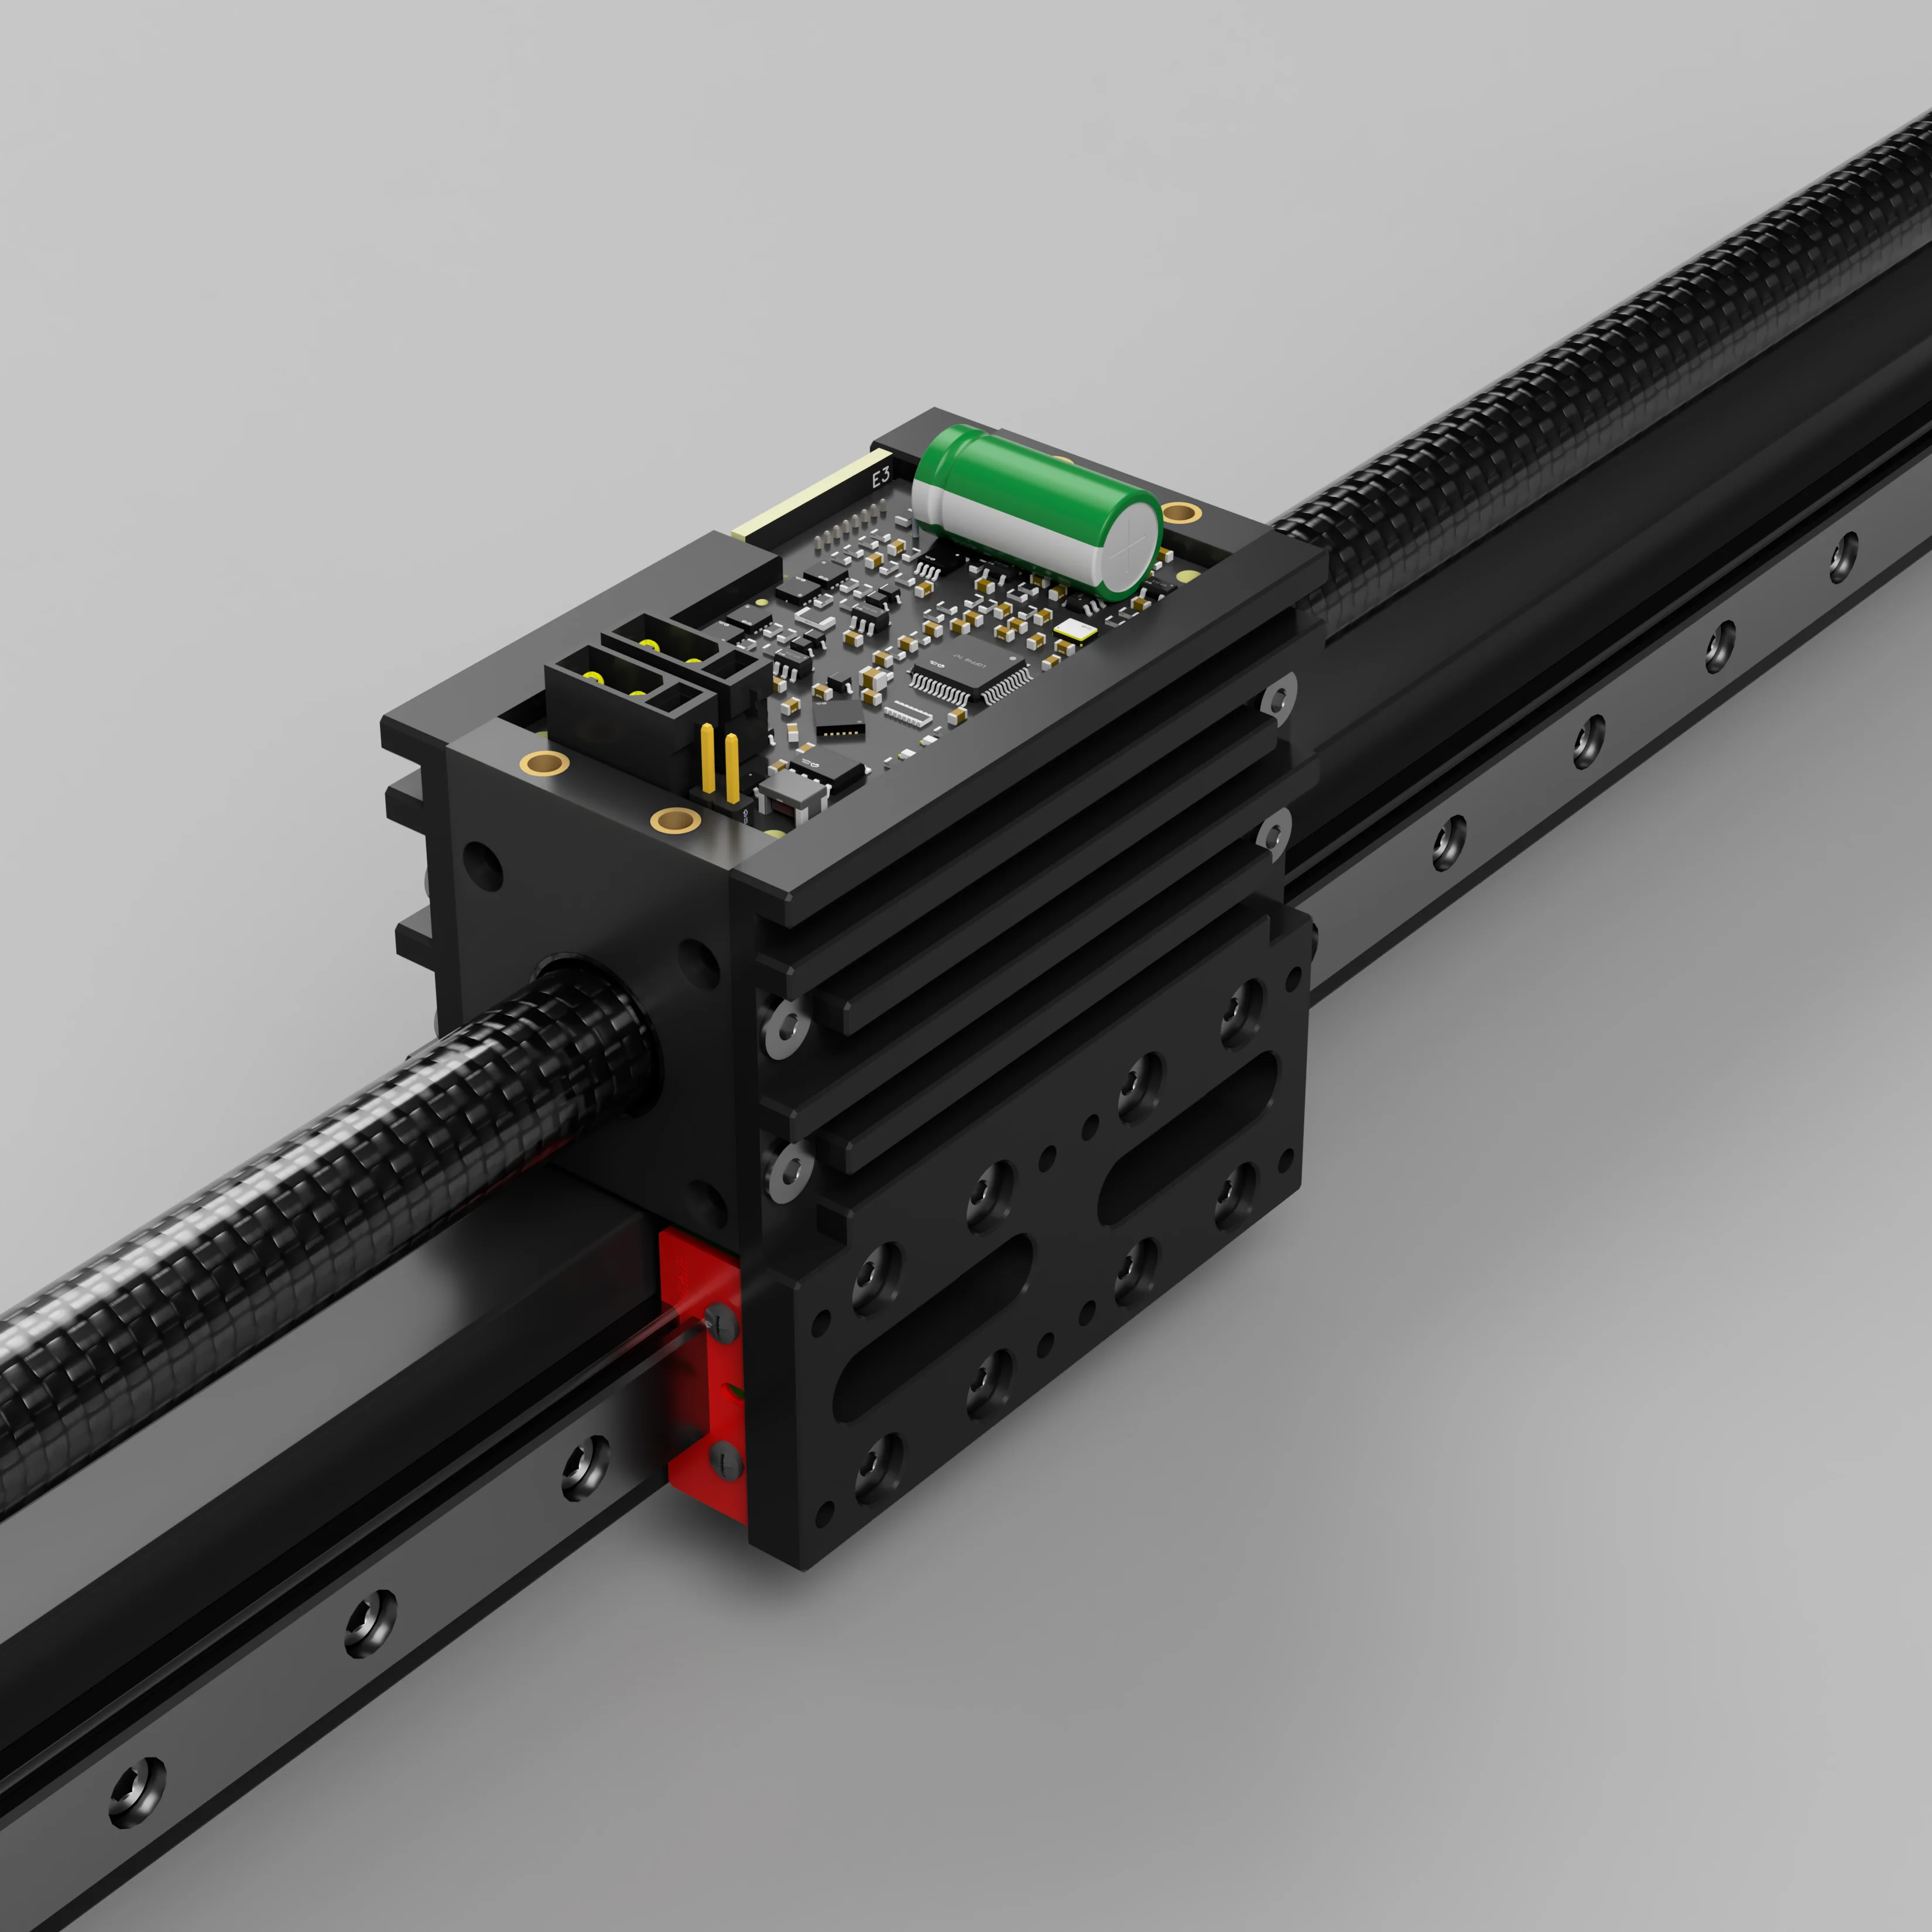
Tubular Linear Motors
Ironless tubular structure with magnetic-scale + encoder closed loop, built for 3D printers and PNP(pick-and-place) machines.
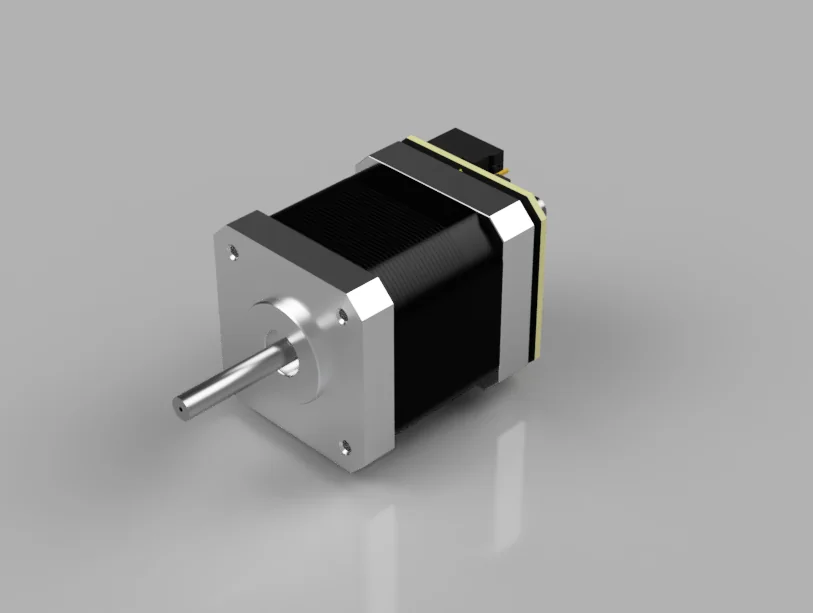
Stepper Servo Motors
42 mm flange closed-loop stepper servo with encoder feedback, dual protocols out of the box.
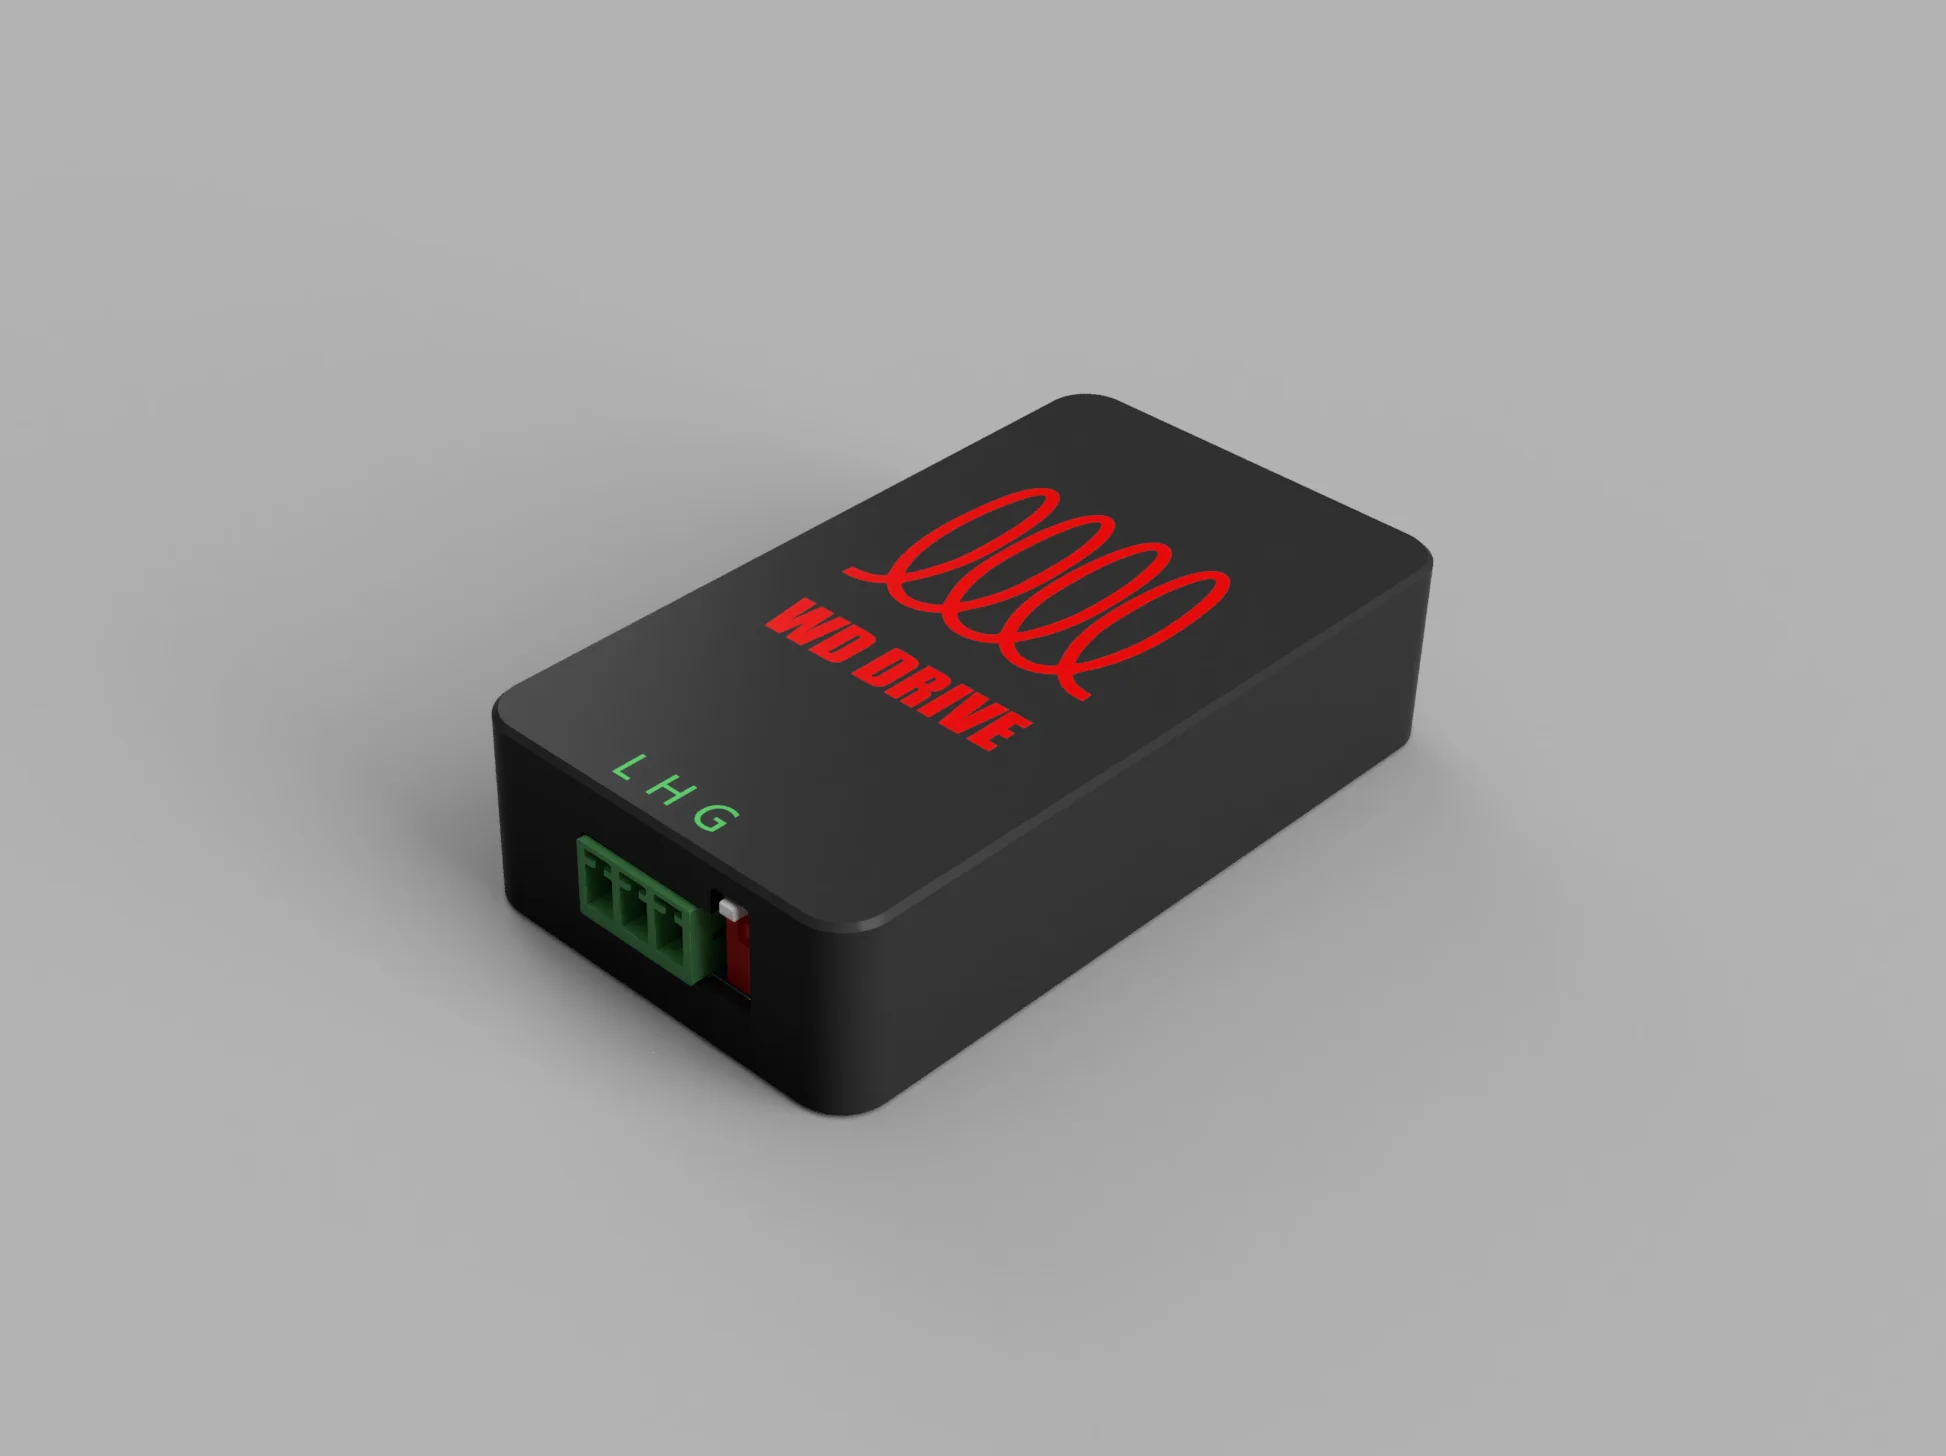
USB-CAN Adapters
CANopen master or USB-CAN bridge — two functions in one device.
03 What We Stand For
Three words we work by every day
Open
Native CANopen CiA402 and Klipper support, USB-CAN built on the open-source candleLight firmware. We don’t lock you in — protocols are public, docs are open, and host software ships with every product.
Focus
Our team has limited resources, so we take each product deep into real desktop scenarios and make it just work: tubular linear, stepper servo, USB-CAN.
Practical
Consumer pricing, small-batch availability, direct engineer contact. We don’t promise "ten years maintenance-free" — we promise "someone reachable, with a clear answer".
04 Technical Ecosystem
Standing on giants' shoulders without locking anyone out
CANopen · CiA 402
The standard servo protocol with 8 operating modes: profile position / velocity / torque, homing, interpolated position, and cyclic sync position / velocity / torque. Our motors support all of them natively; pair them with the USB-CAN adapter for multi-axis debugging.
CAN in Automation ↗3D Printer FirmwareKlipper
The open-source 3D printer firmware ecosystem. Our motors and adapters are pre-tuned for Klipper wiring, baud rates and protocols — 3D printers work out of the box.
klipper3d.org ↗USB CAN FirmwarecandleLight
The USB-CAN adapter is built on the open-source candleLight_fw firmware — plug & play with Linux SocketCAN, no hardware lock-in.
github.com/candle-usb/candleLight_fw ↗05 Contact Us
Selection & Technical Consulting
midi7@wd-drive.com
9:00 – 18:00 (GMT+8)
Reply within 12 h.
Team
You talk directly to an engineer.
Selection, firmware and host-software questions, answered in one conversation.
Open Documentation
Protocol docs, wiring guides and host software
included with every product
Social Media
- Bilibili · midi700
- YouTube · @midi700
- WeChat · Midi7i