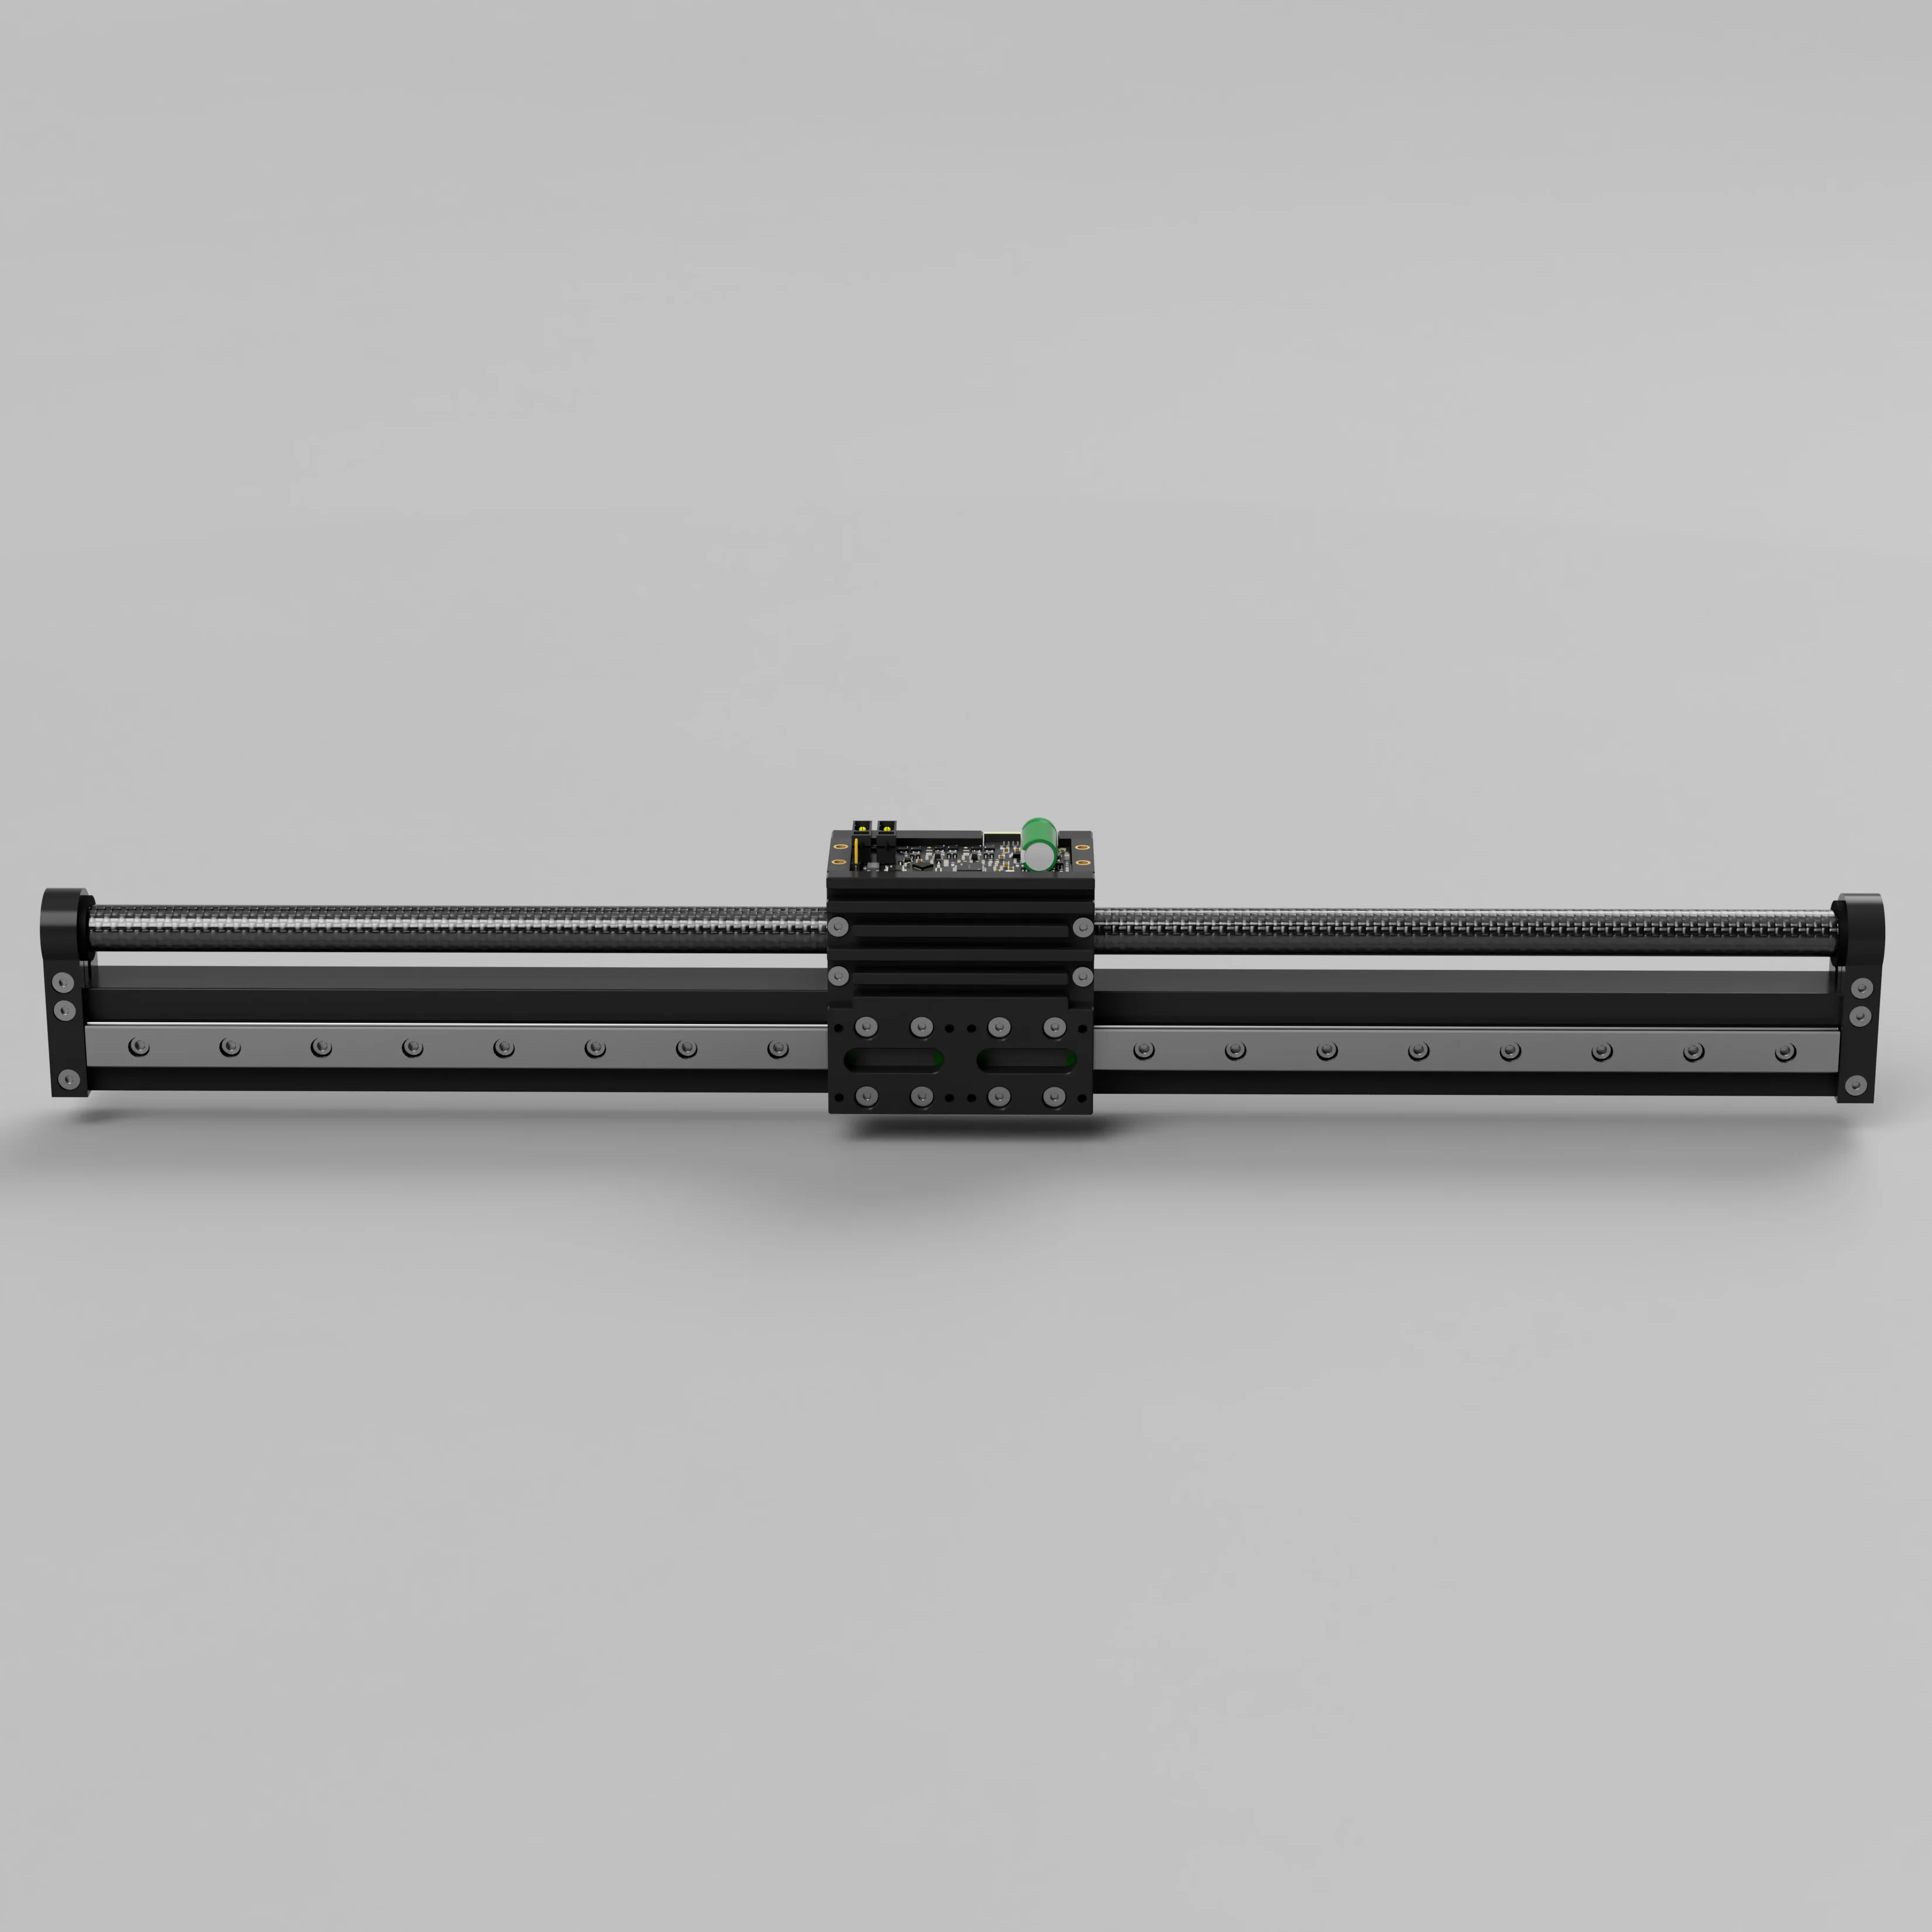
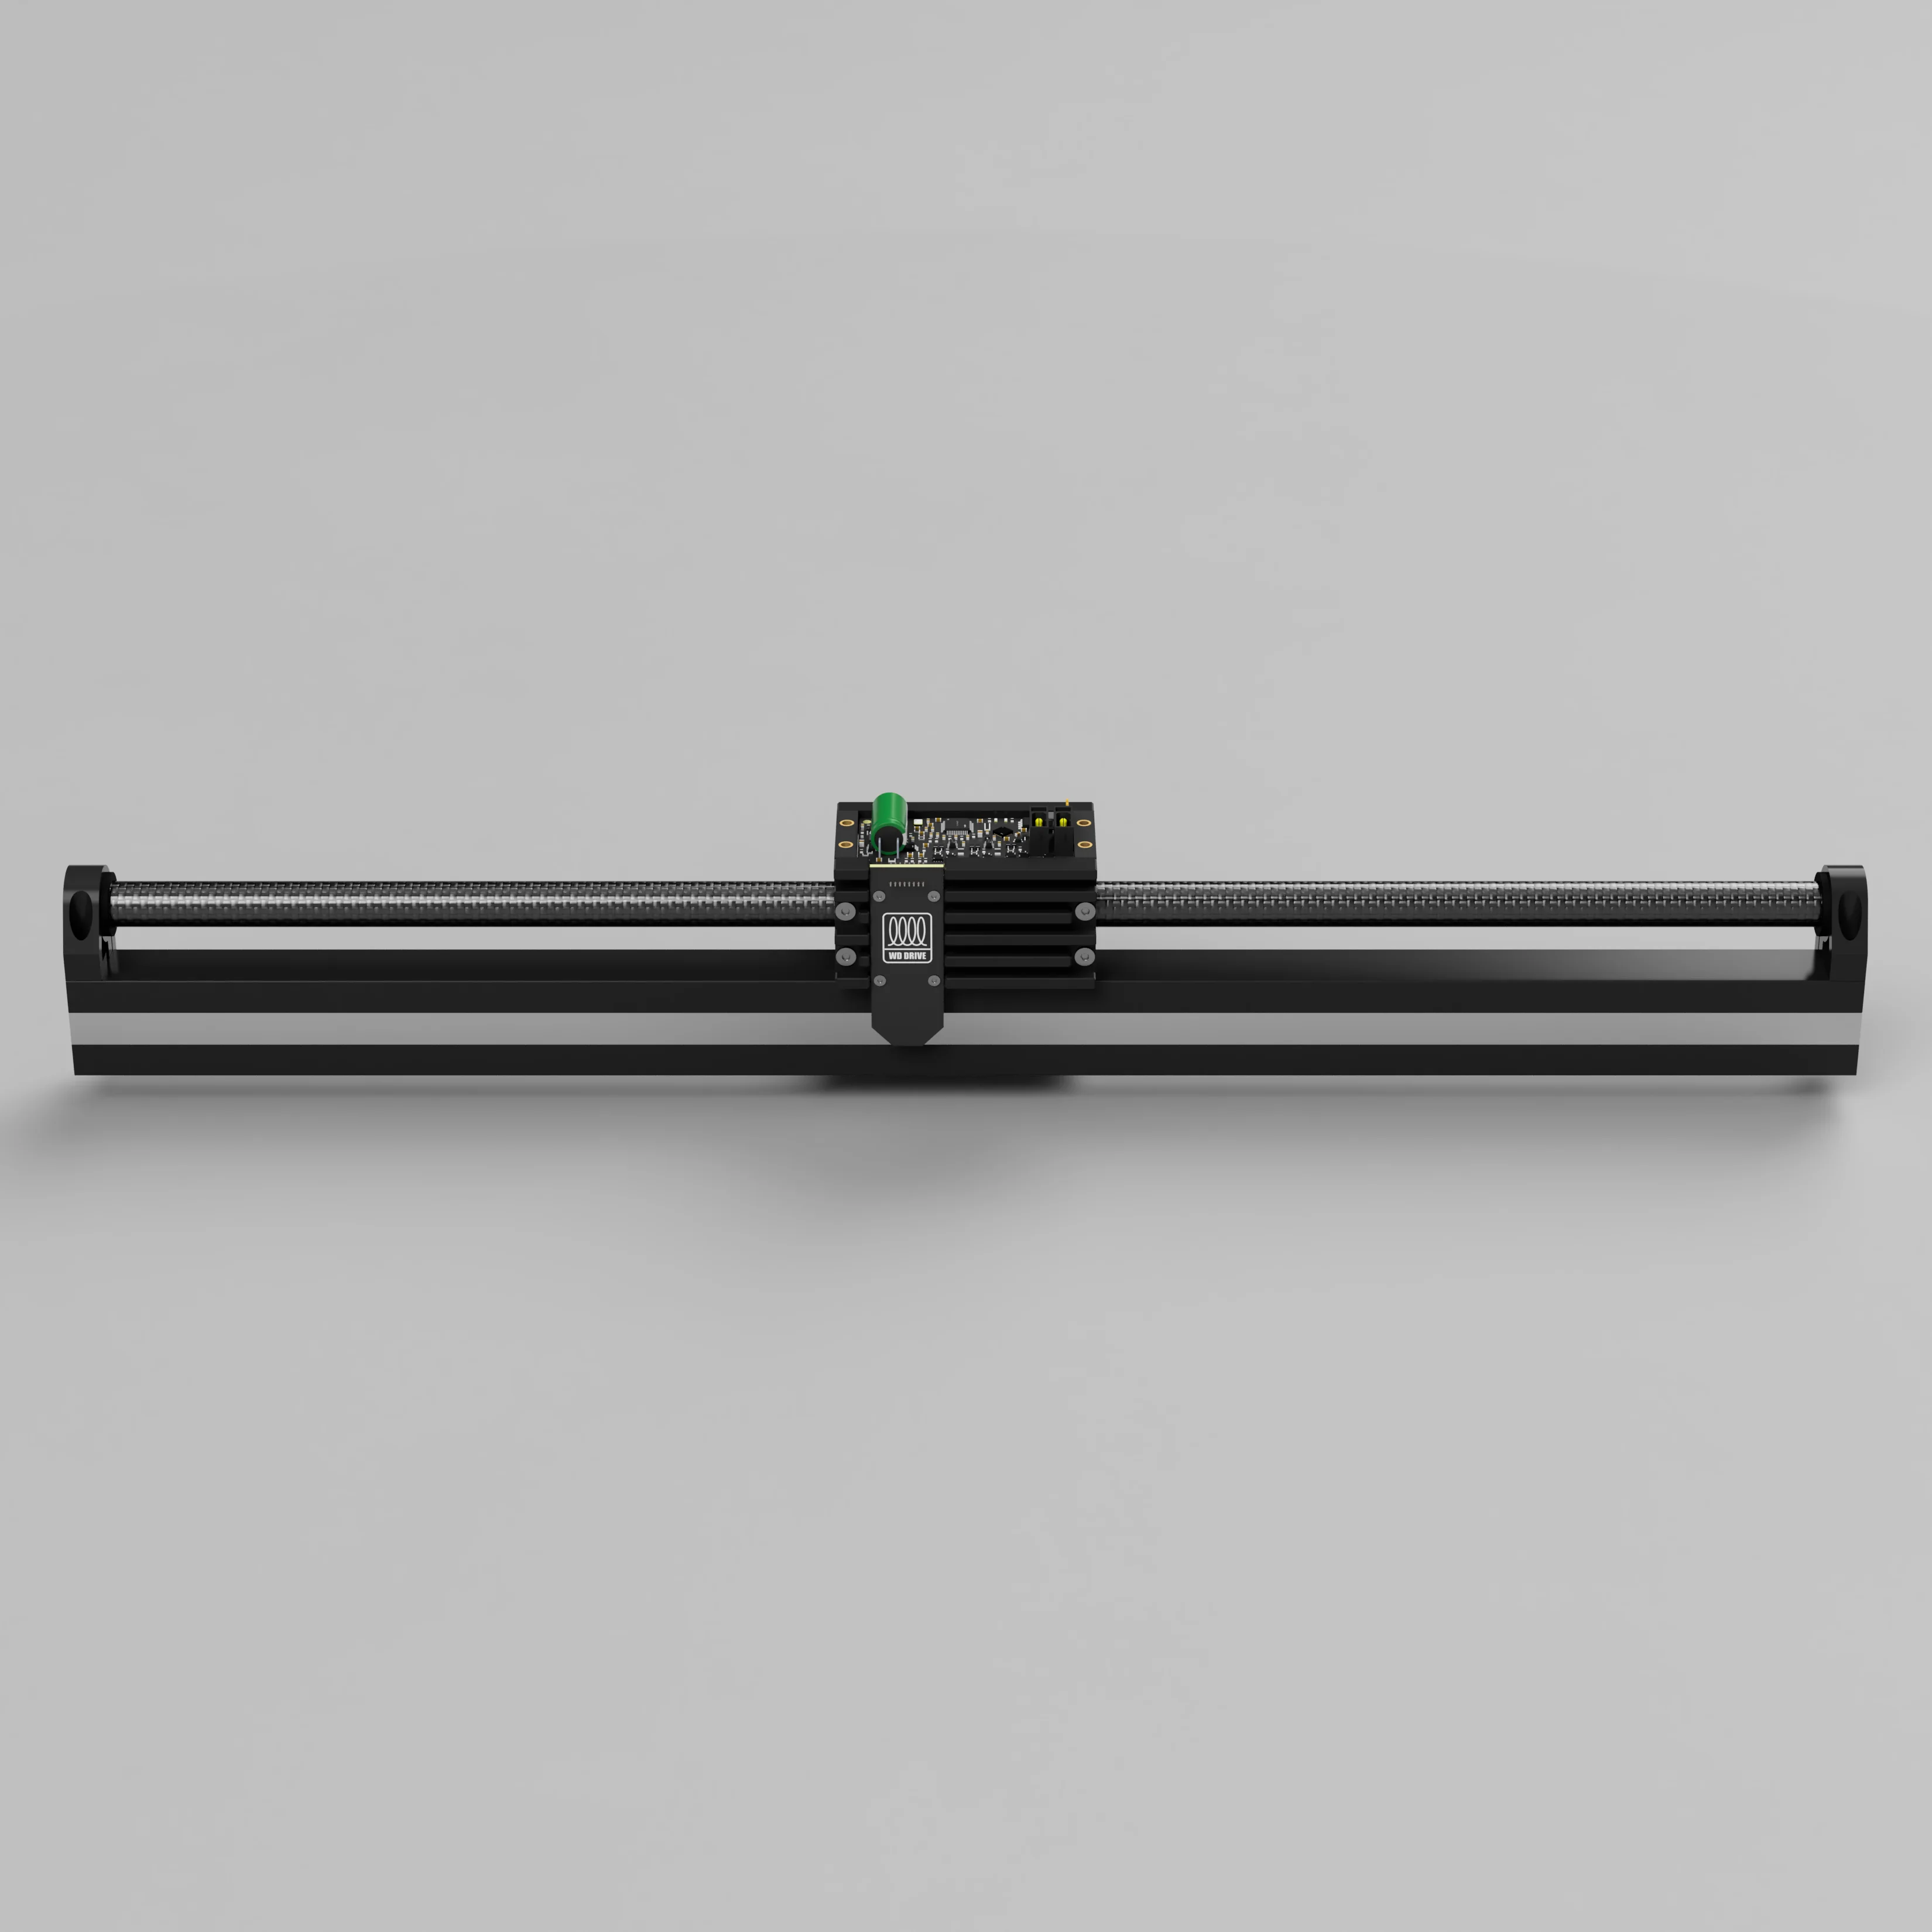
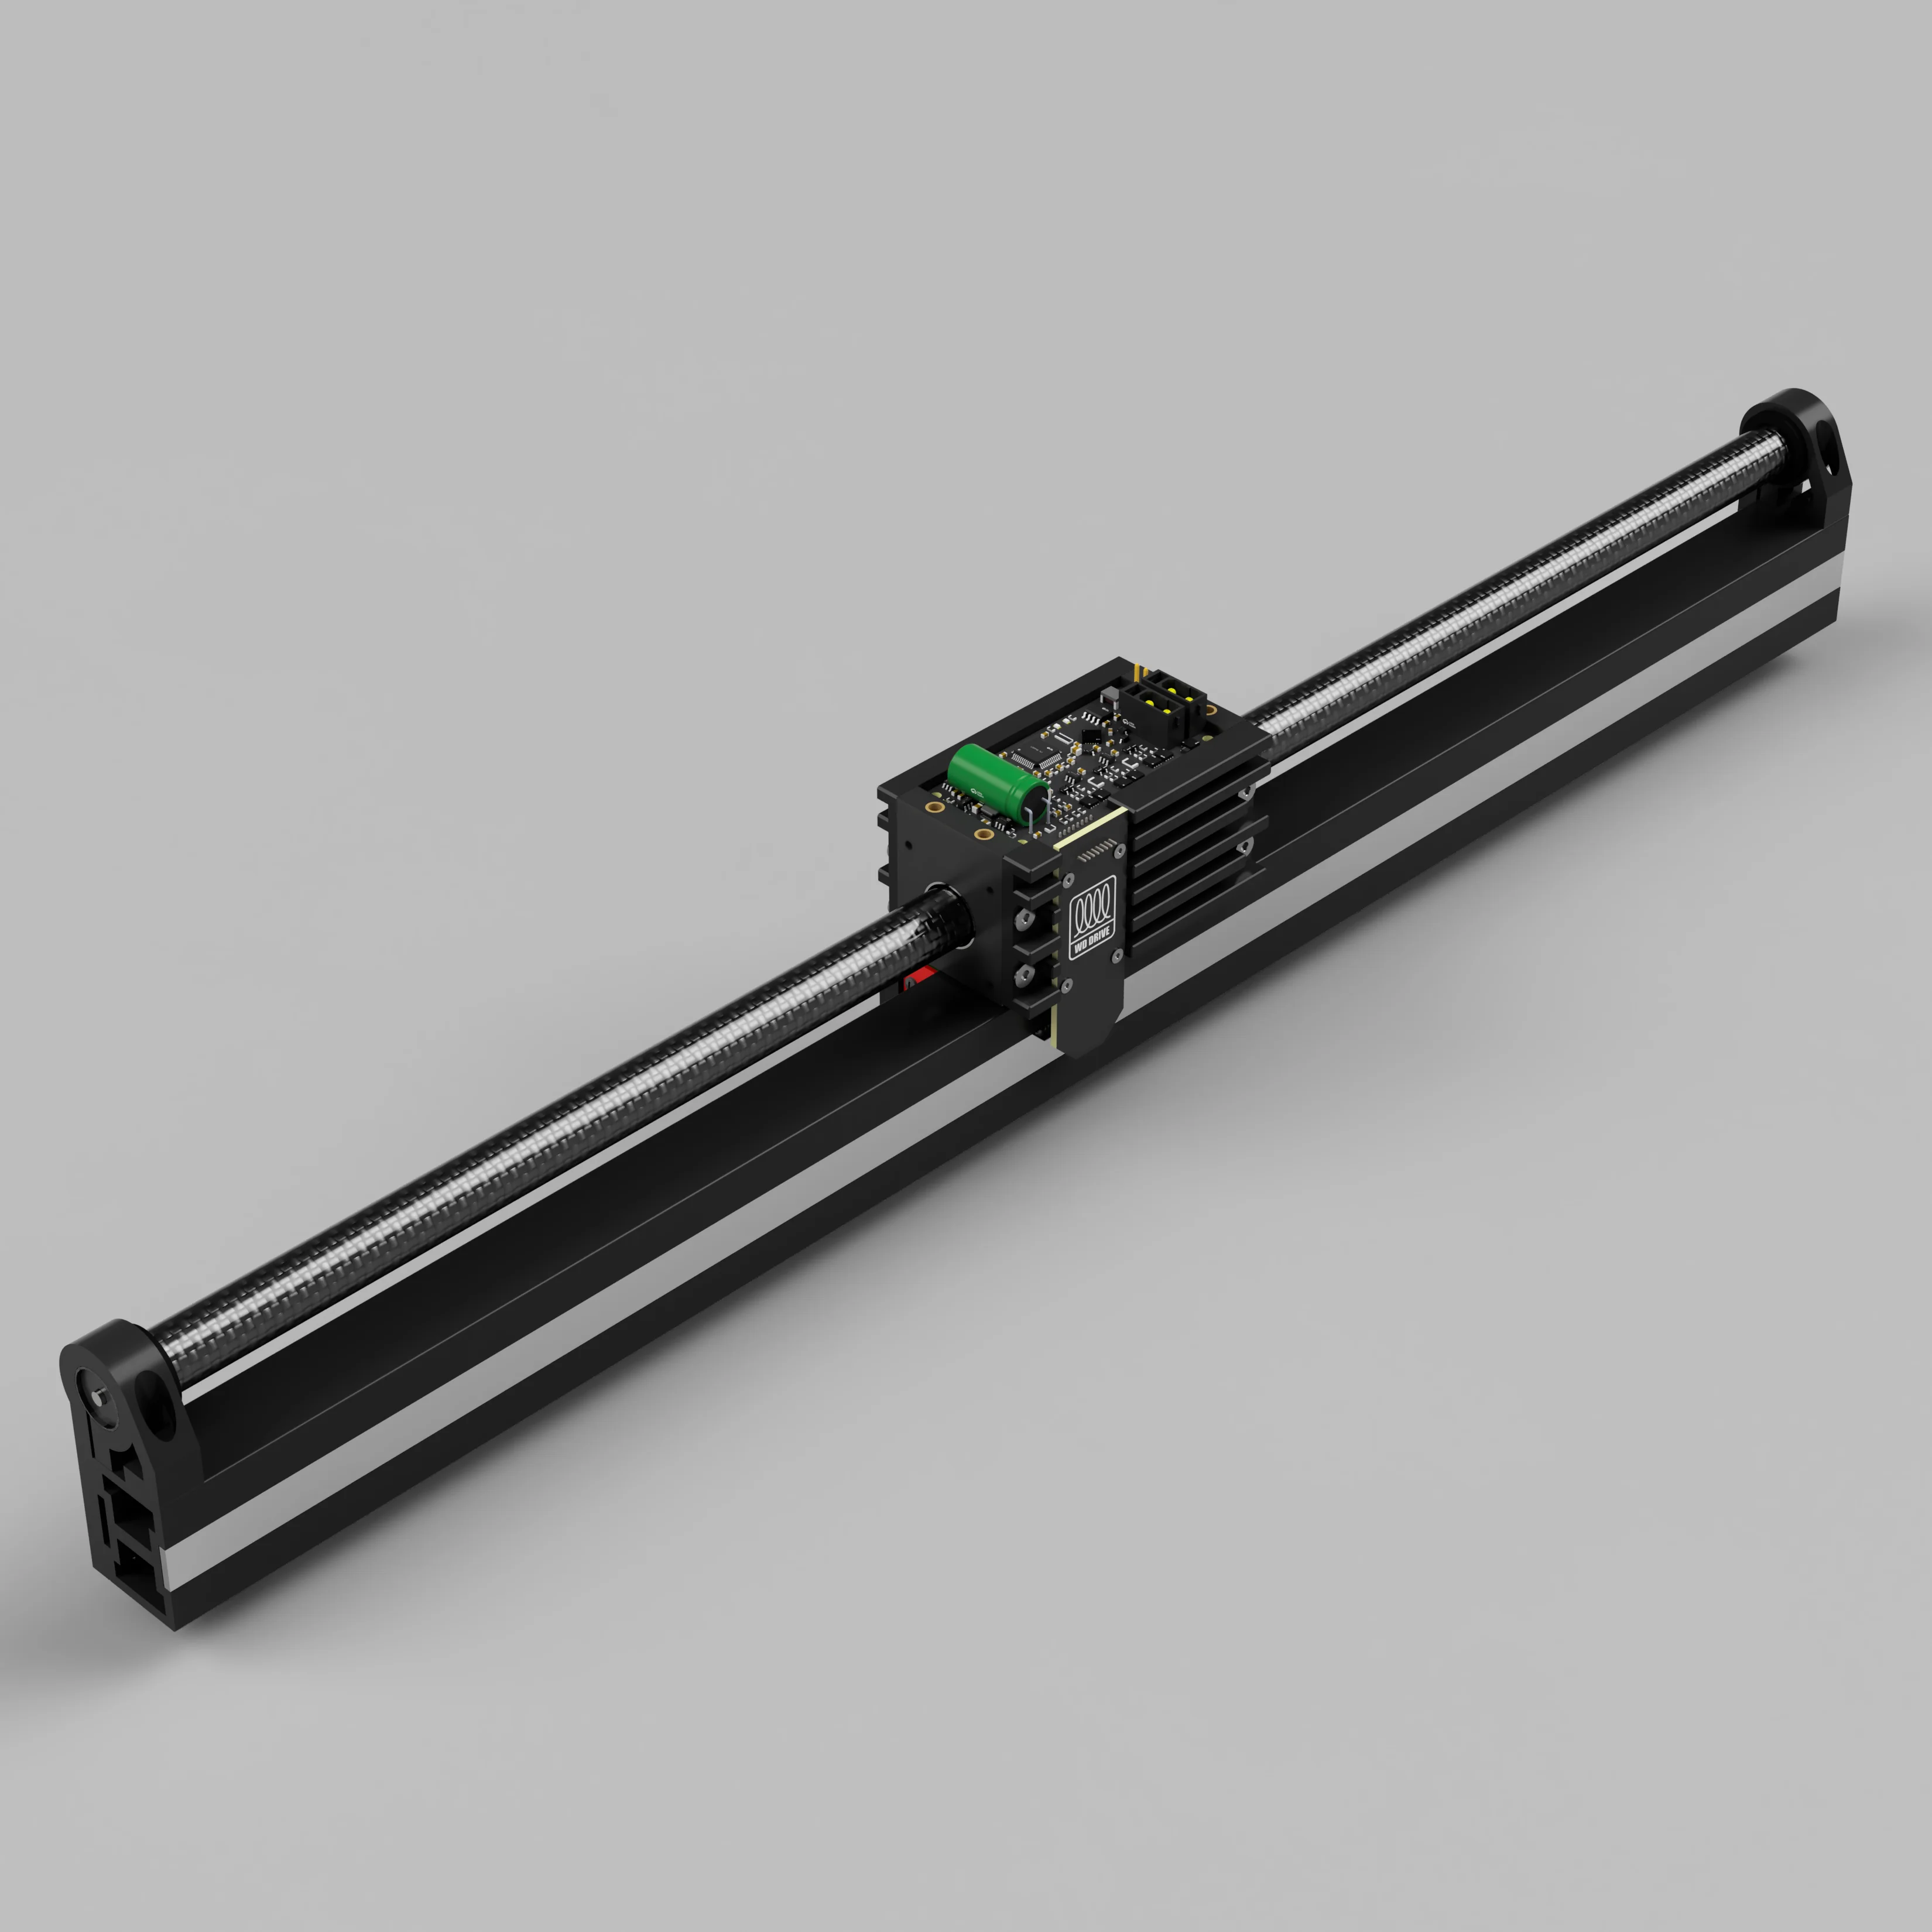
Tubular Linear Motors
Tubular Linear Motor
Ironless tubular · magnetic-scale closed loop · CANopen CiA402 + Klipper dual-protocol direct drive
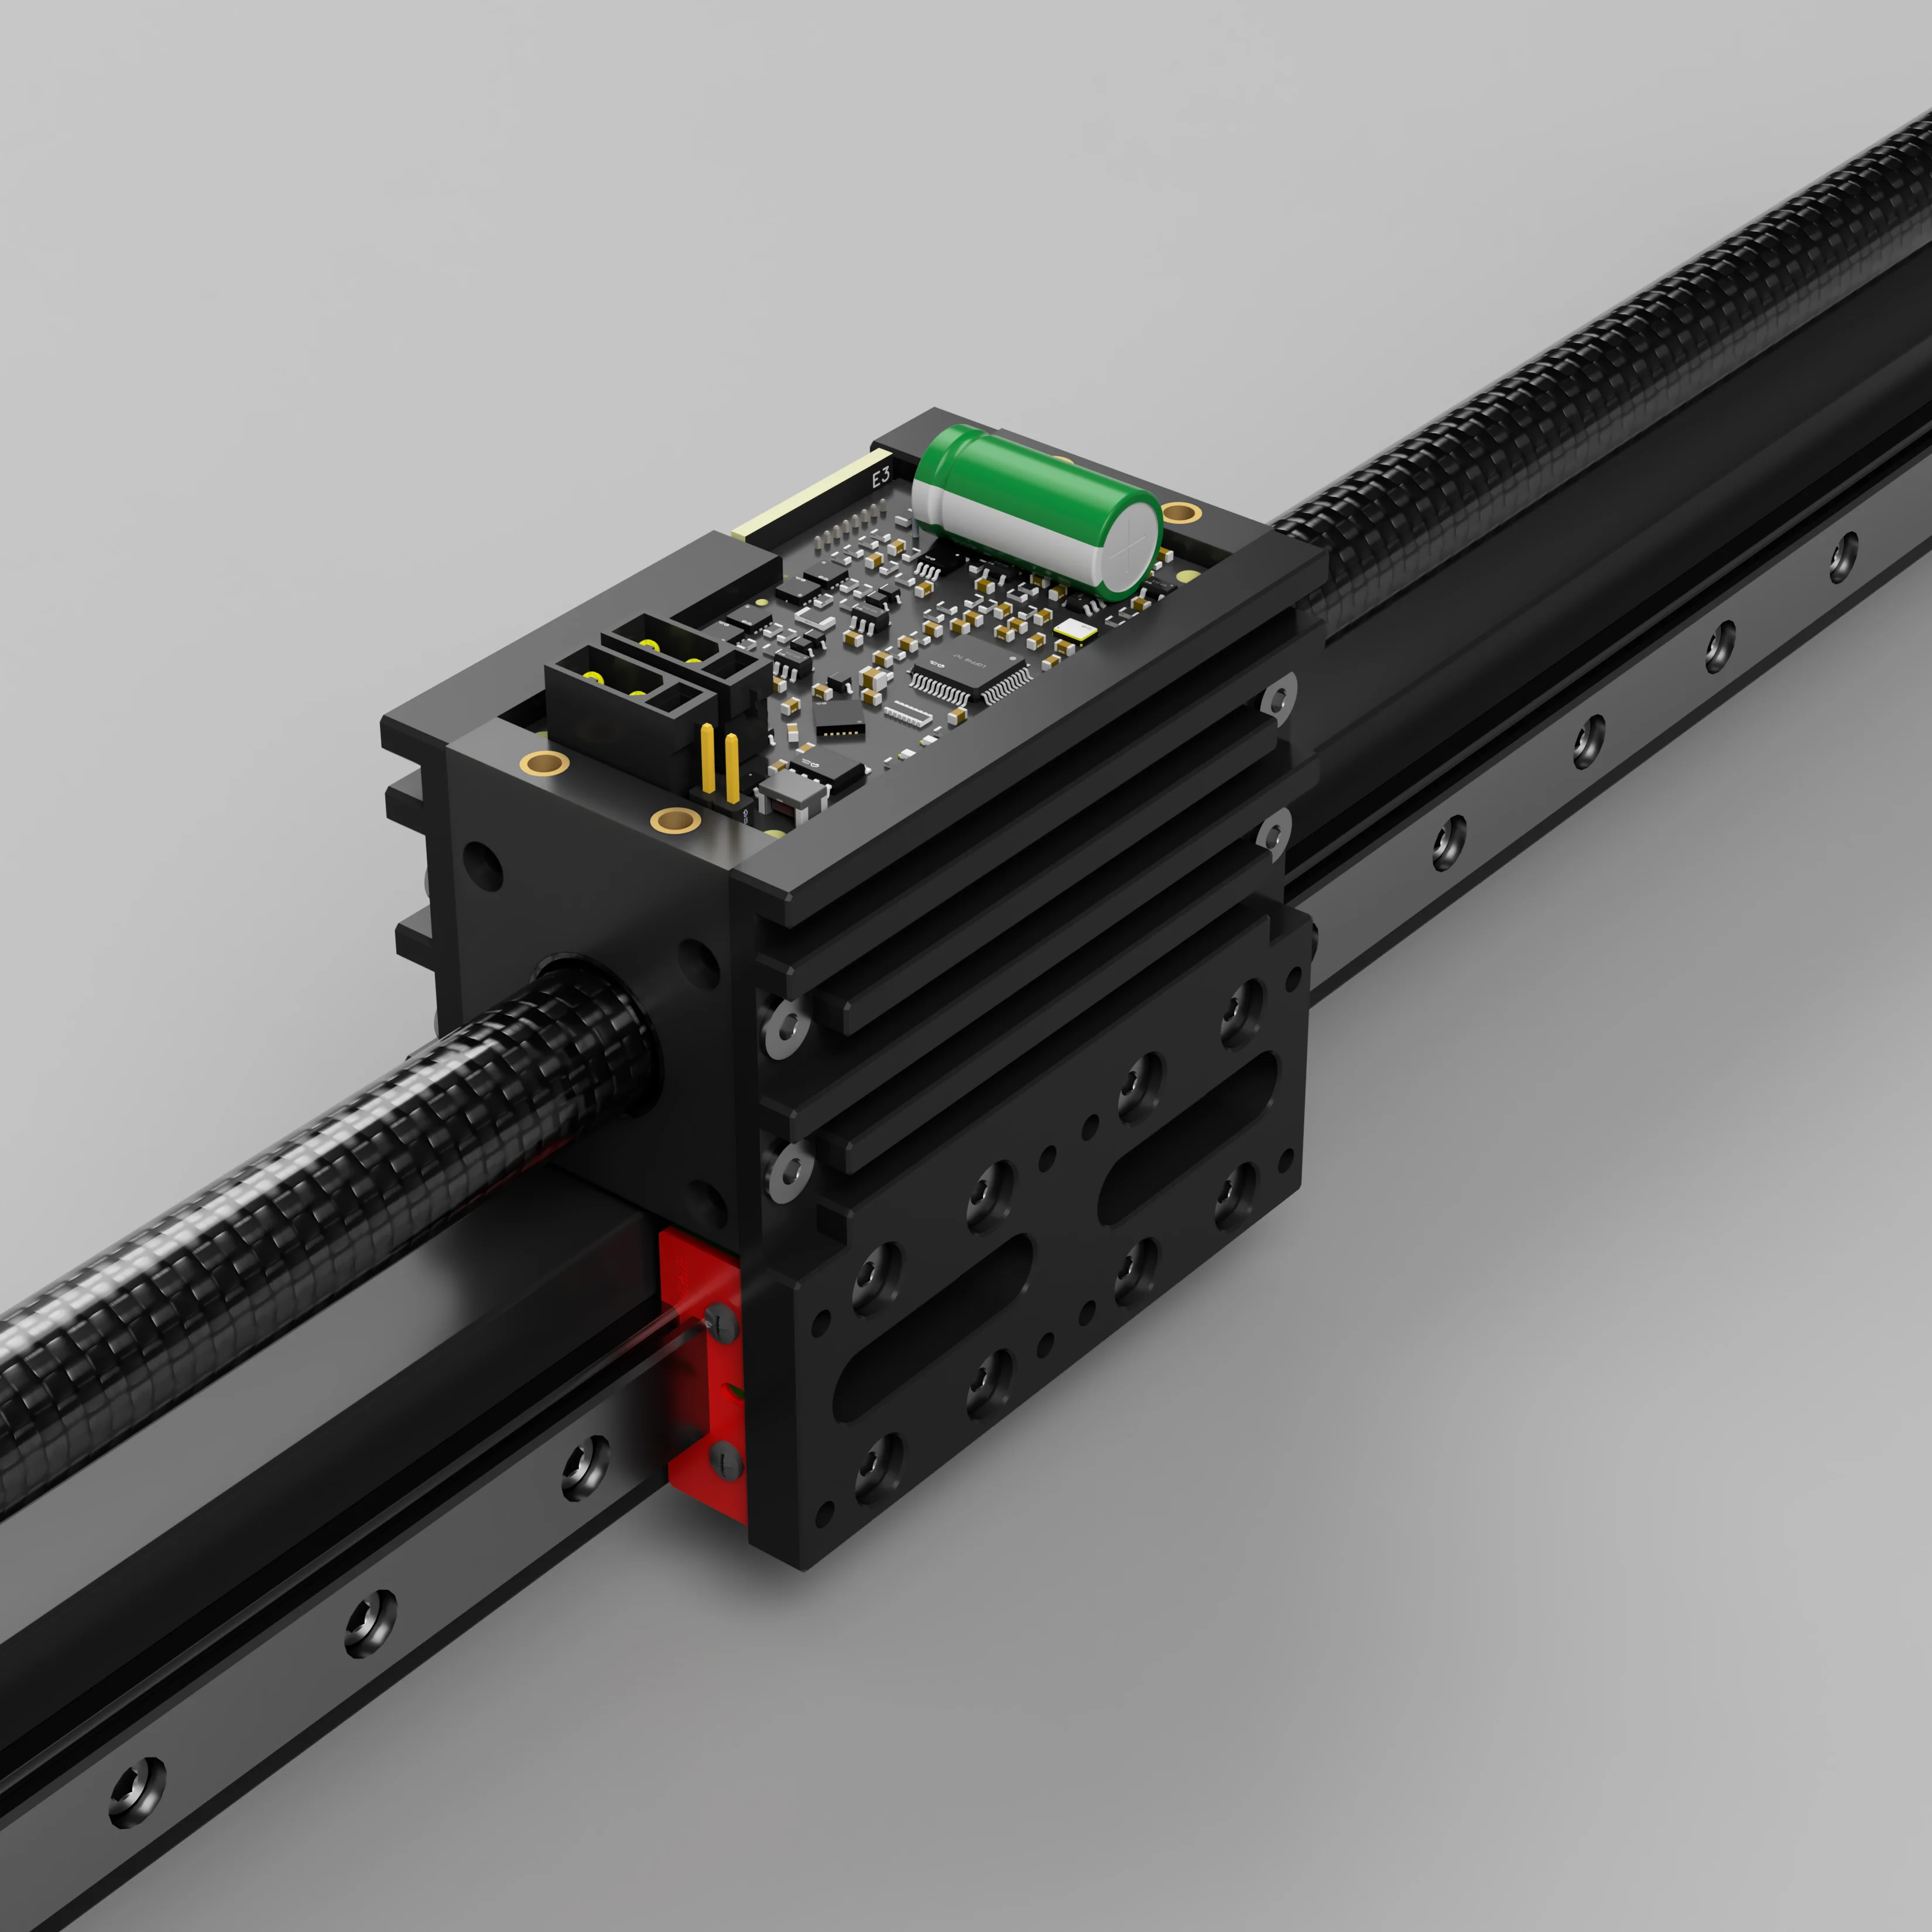
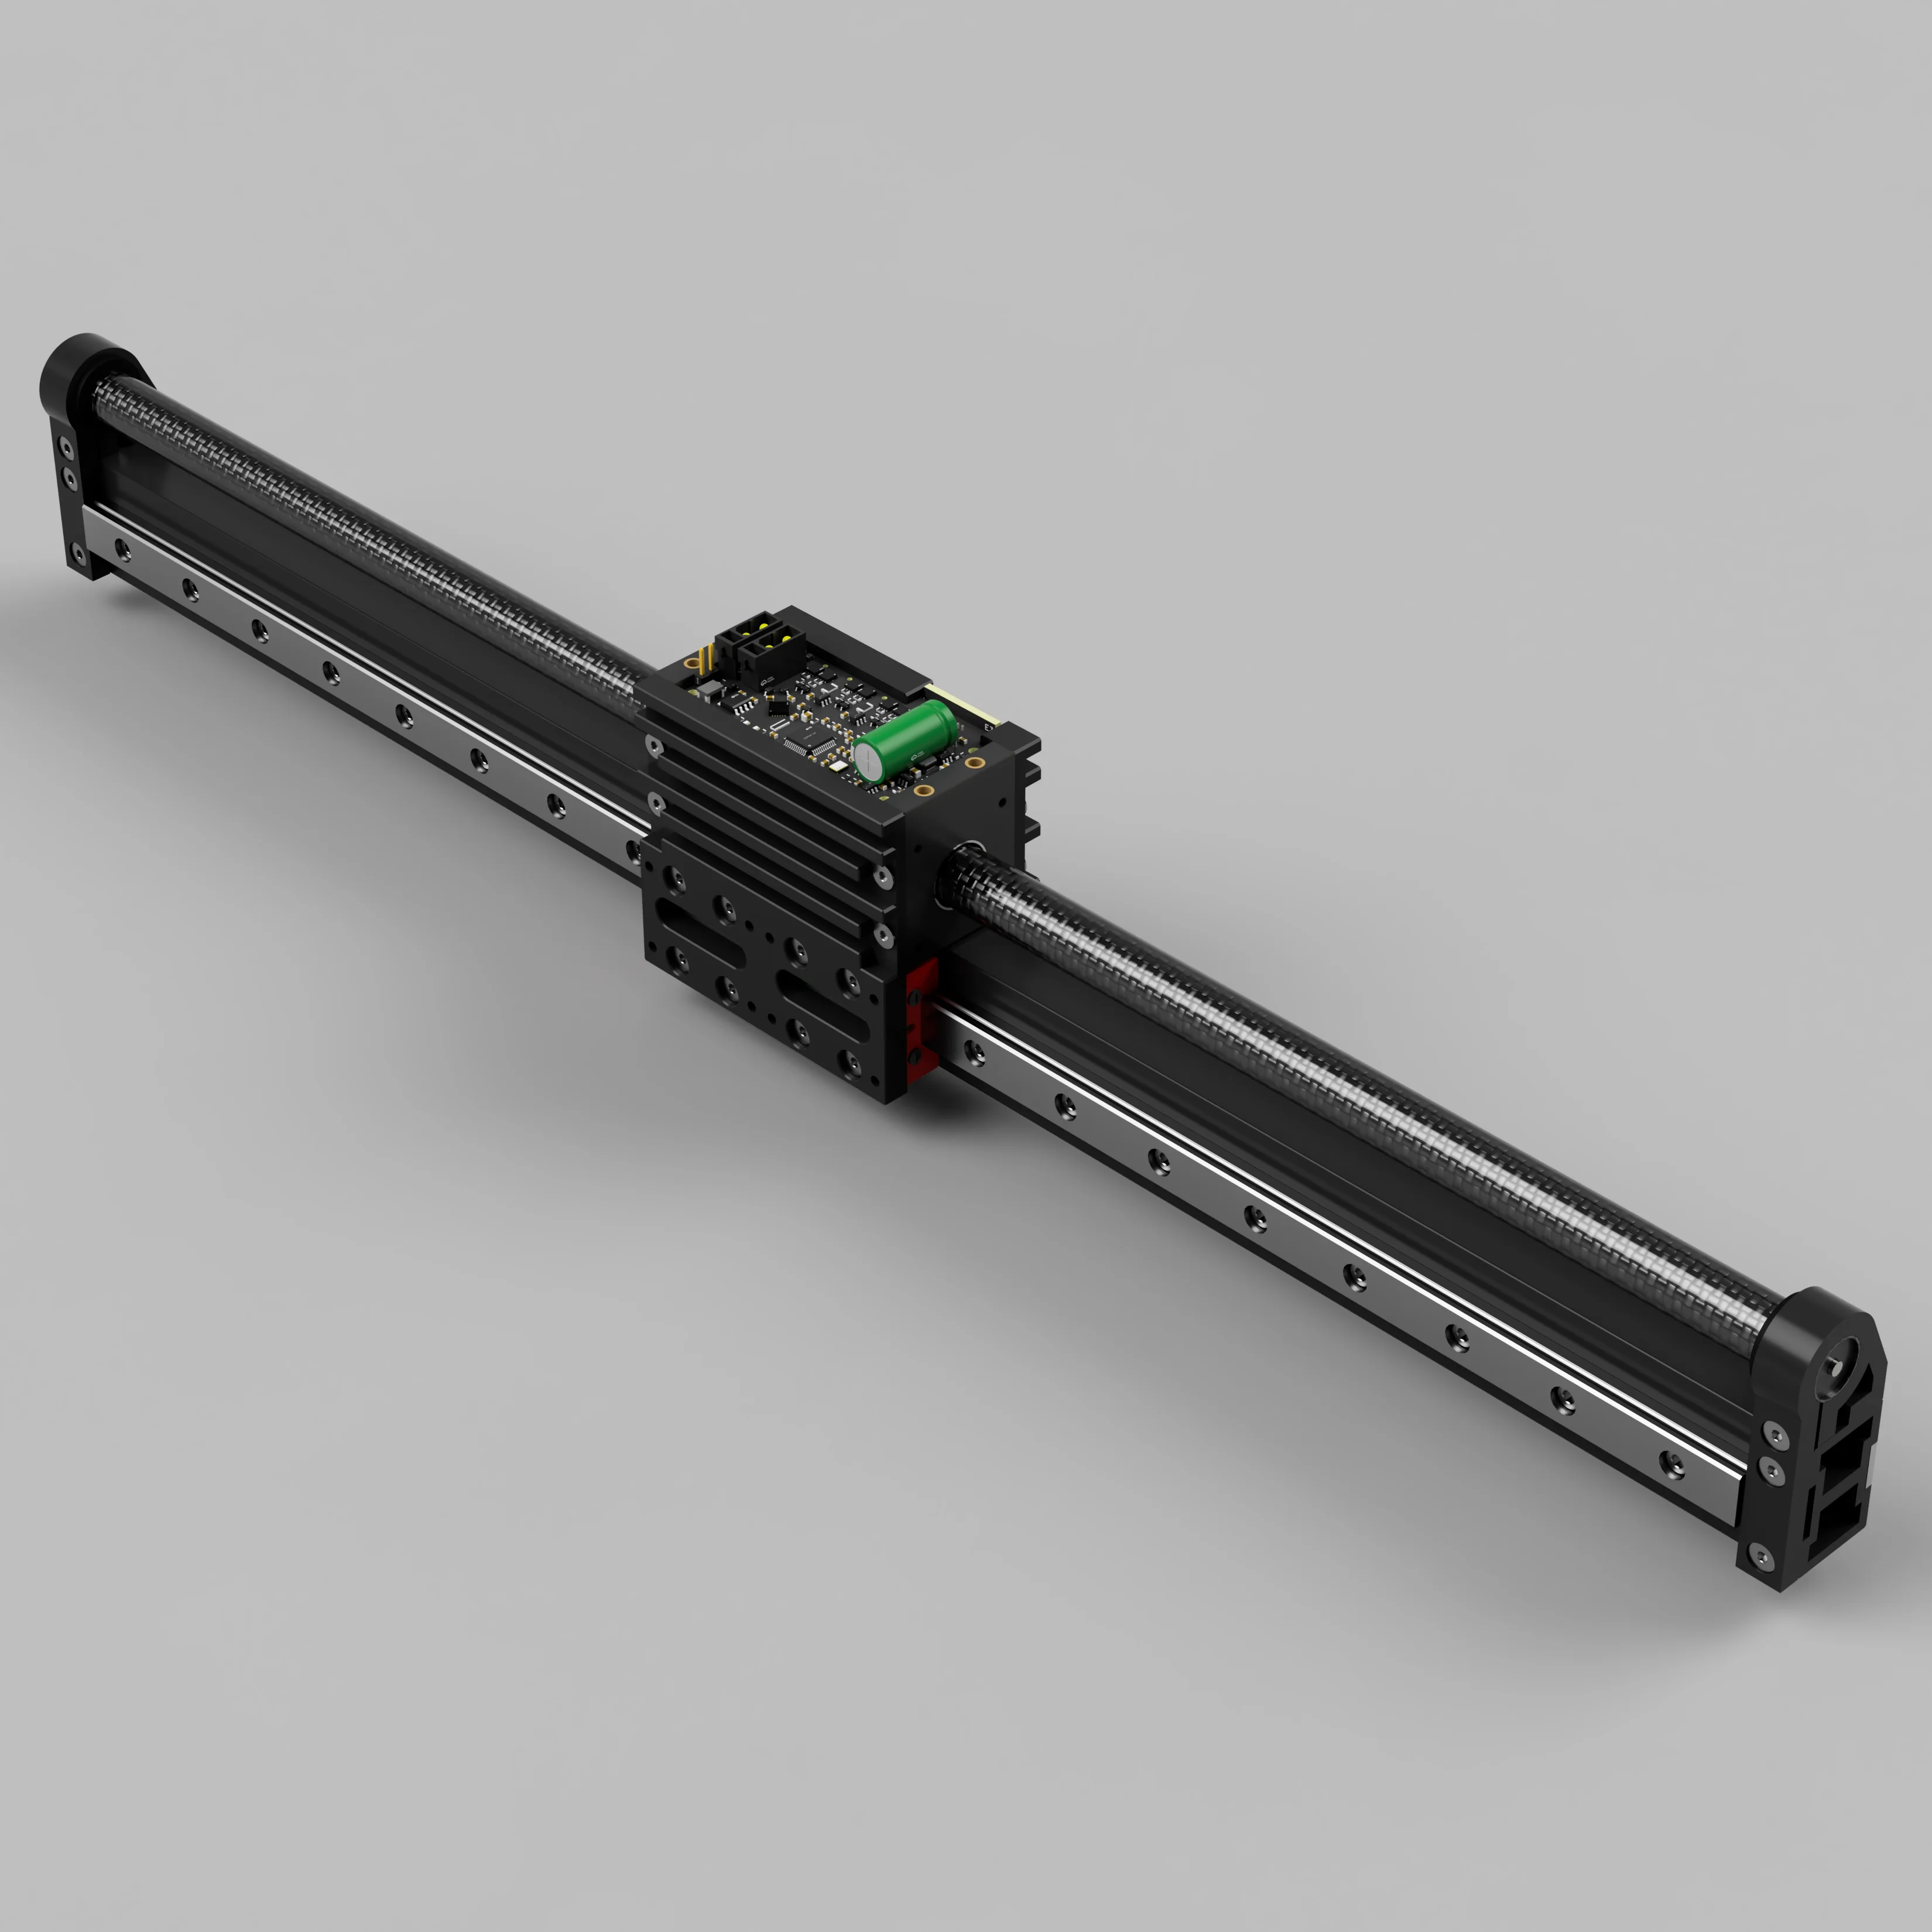
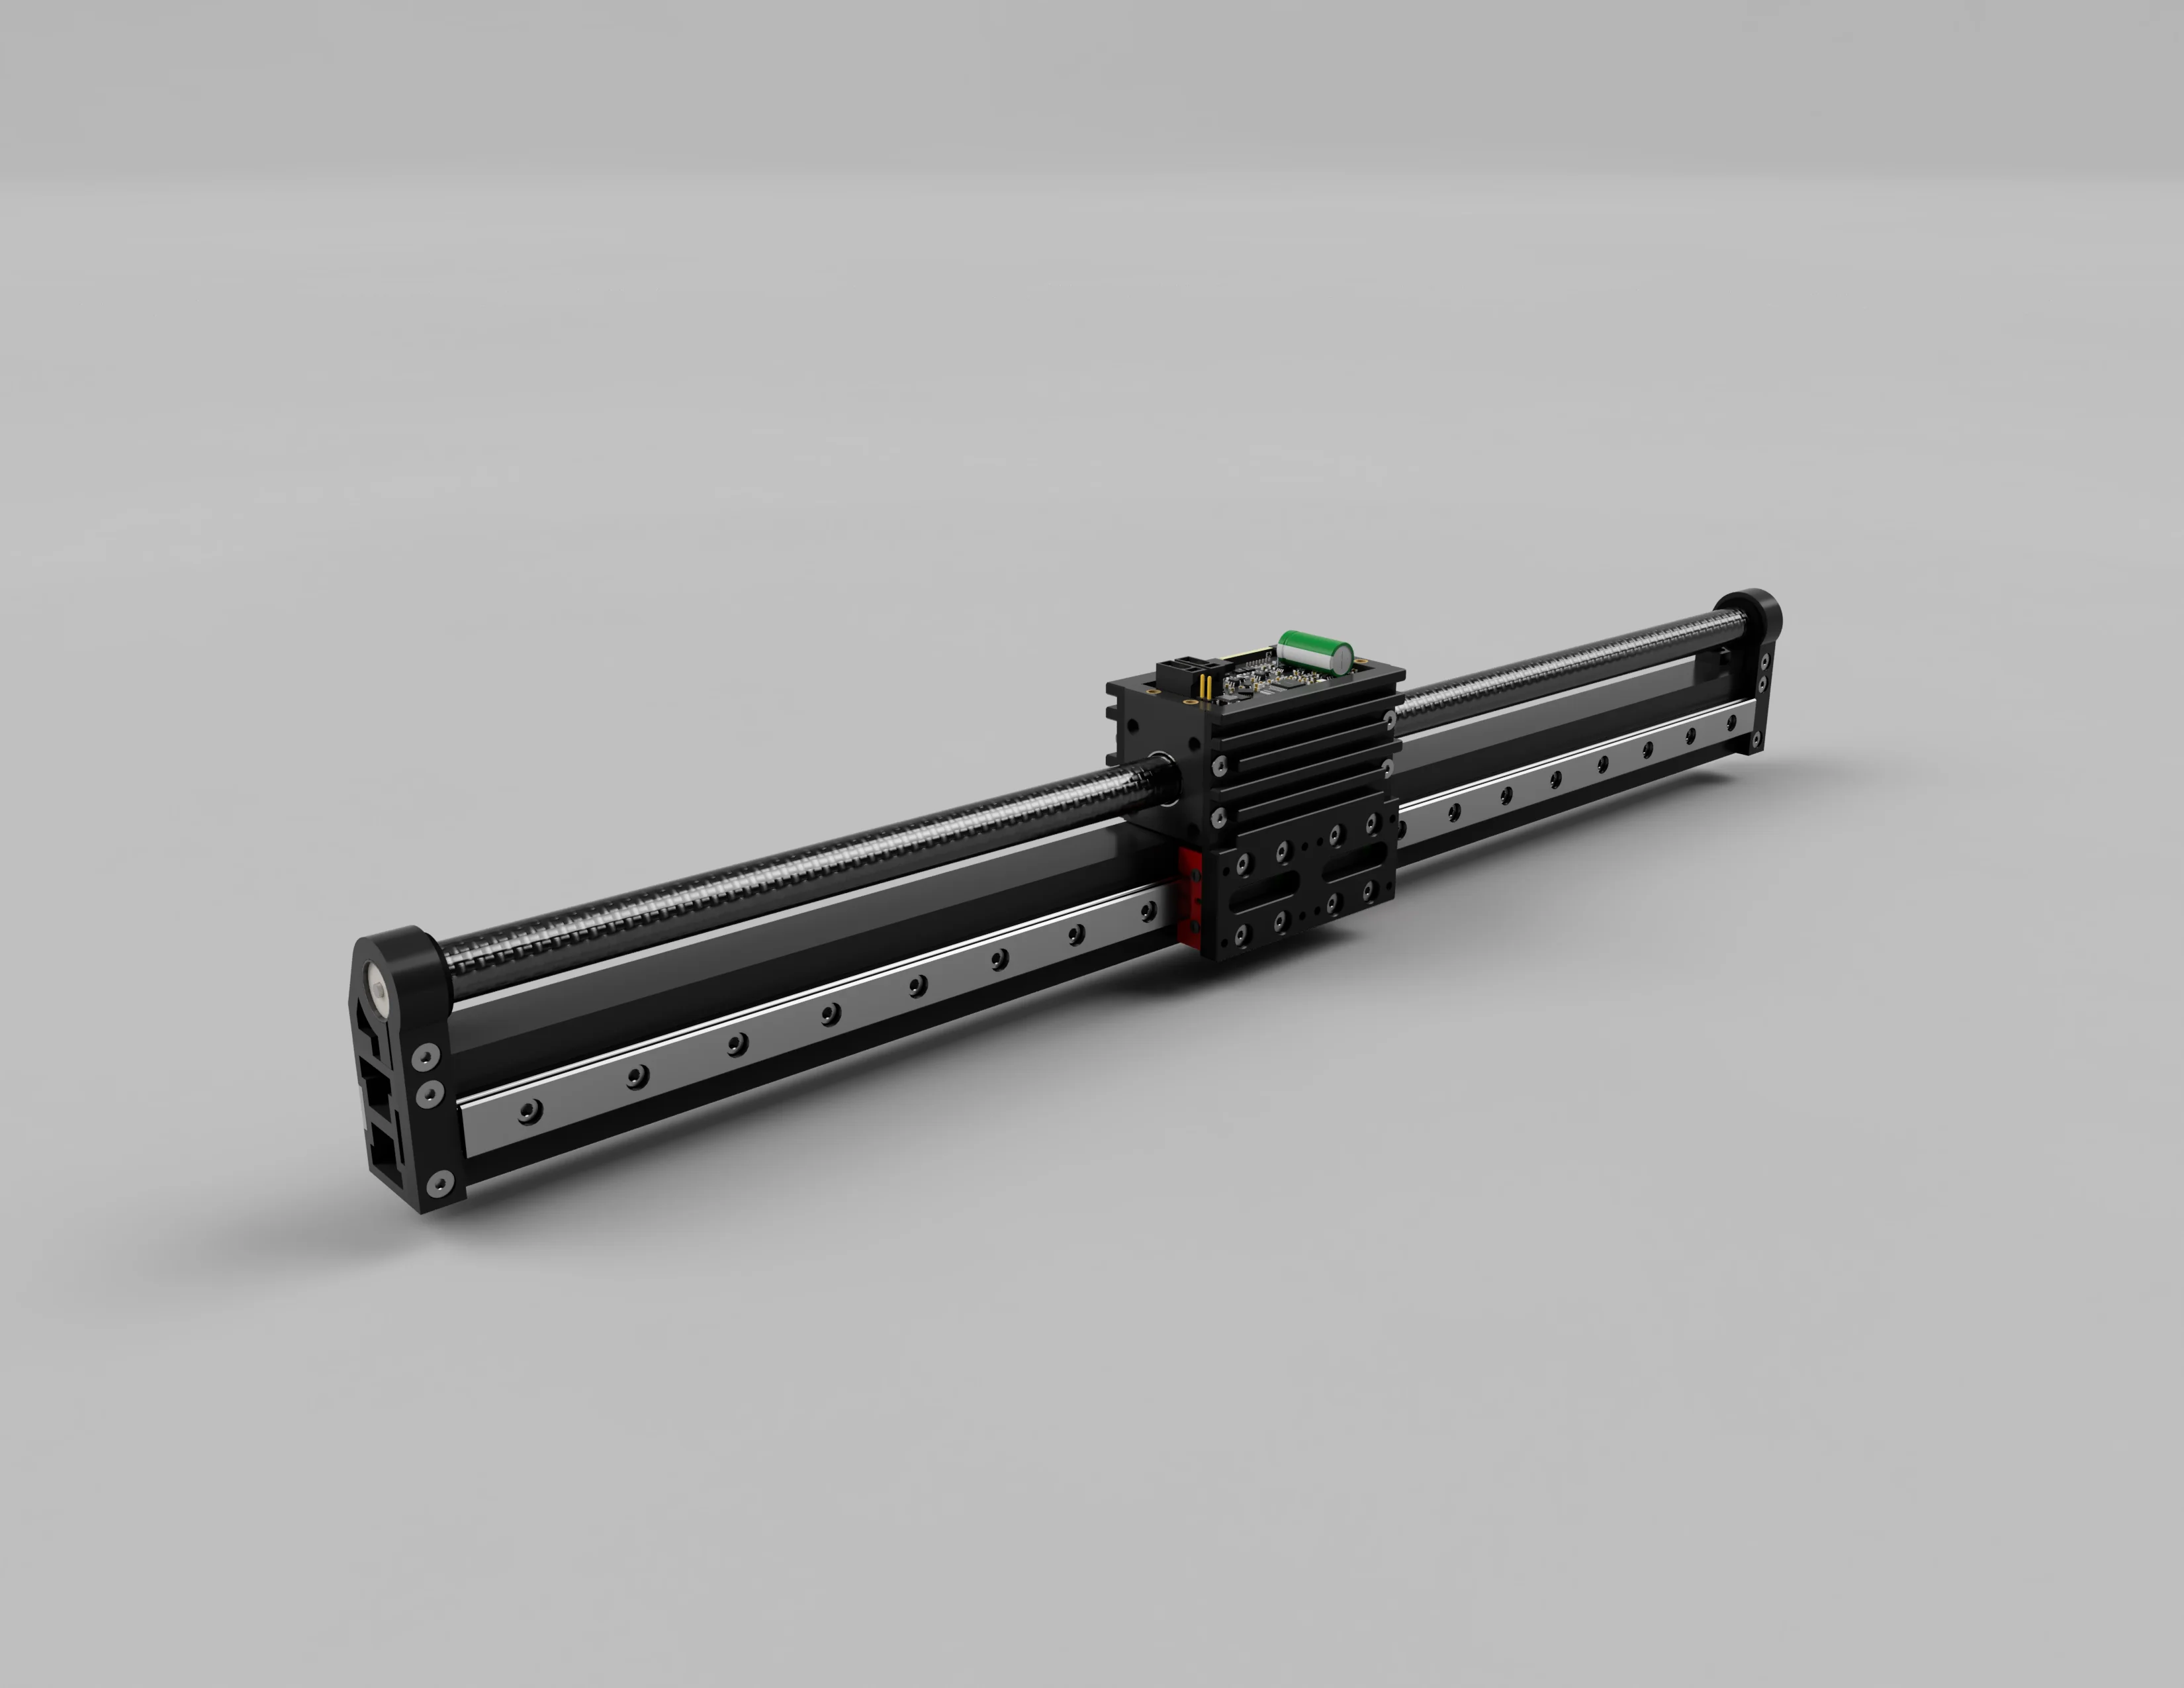
Ironless tubular linear motor: no iron teeth or magnetic attraction between mover and stator, giving smooth, crawl-free motion at low speeds. Integrated magnetic-scale + encoder closed-loop feedback works with CANopen CiA402 servo control or Klipper firmware out of the box. Optimized for 3D printers and desktop PNP(pick-and-place) machines — balancing performance, ease of use, and consumer-level cost.
- Structure
- Ironless tubular
- Feedback
- Magnetic scale + encoder
- Protocol
- CANopen · Klipper
- Effective travel
- 300 / 400 / 500 / 600 mm
01 Features & Advantages
Why choose Tubular Linear Motor
- 01
High speed, high acceleration, high precision
- 02
Ironless structure: zero cogging force, zero magnetic attraction, smooth low-speed motion
- 03
Magnetic-scale + encoder closed-loop feedback — no step loss
- 04
Native support for all 8 CANopen CiA402 operating modes (position / velocity / torque / homing / interpolation / cyclic sync)
- 05
Native Klipper firmware support — plug & play for 3D printers
- 06
Travel and dynamics optimized for 3D printers and desktop PNP(pick-and-place)
- 07
Ring winding cuts magnetic flux lines vertically through 360°, maximizing flux utilization
- 08
Homing without limit switches
02 Technical Specifications
Tubular Linear Motor
※ Ratings are typical values at 25 °C ambient temperature; see the datasheet for detailed tolerances.
Motor Parameters
| Structure | Ironless coil |
|---|---|
| Cogging force | Zero |
| Magnetic attraction | Zero (ironless) |
| Pole pitch τ | 10 mm (N-S pole distance) |
| Guide rail | MGN12 |
| Housing material | Metal, non-magnetic |
| Motion direction | Bidirectional (drive-controlled) |
Force & Electrical Parameters (25 °C)
| Continuous force Fe max | 10.0 N |
|---|---|
| Peak force Fp max | 34.0 N |
| Continuous current Ie max | 2.3 A |
| Peak current Ip max | 7.8 A |
| Force constant kF | 4.34 N/A |
| Flux linkage ψ | 5.32 mwb |
| Phase resistance R | 2.3 Ω |
| Phase inductance L | 932 µH |
| Rated voltage | 48 V DC |
| Max motor voltage | < 54 V DC |
Travel Specifications (S=400mm)
| Effective travel S max | 300 / 400 / 500 / 600 mm |
|---|---|
| Positioning accuracy | ±0.005 mm |
| Max acceleration ae max | 86.8 m/s² |
| Max speed ve max | 5.8 m/s, increases with travel S |
| Mover weight | 380 g |
| Total weight | 1.5 kg, increases with travel S |
Electrical & Environment
| Operating temperature | −20 … +100 °C |
|---|---|
| Recommended ambient | -20 … +70 °C |
| Positioning | Desktop consumer grade |
Operating Modes · CiA 402
| PP | Profile Position |
|---|---|
| PV | Profile Velocity |
| PT | Profile Torque |
| HM | Homing |
| IP | Interpolated Position |
| CSP | Cyclic Synchronous Position |
| CSV | Cyclic Synchronous Velocity |
| CST | Cyclic Synchronous Torque |
Closed Loop & Servo
| Feedback | Magnetic scale + encoder |
|---|---|
| Control algorithm | FOC field-oriented control |
| Current loop frequency | 20 kHz |
| Control modes | CiA 402 · 8 operating modes |
| Communication interface | CAN 2.0B (CiA 301) |
| Connectors | XT30 (2+2) PB-M × 2 (in / out) |
| Differential signal lines | CAN_H / CAN_L |
| Power lines | VIN / GND |
| Daisy chain | Supported · multi-device serial |
| Firmware update | CAN online update |
03 Model Naming
Model Naming Rules
Travel options: 300 / 400 / 500 / 600 mm; specifications per the shipping datasheet.
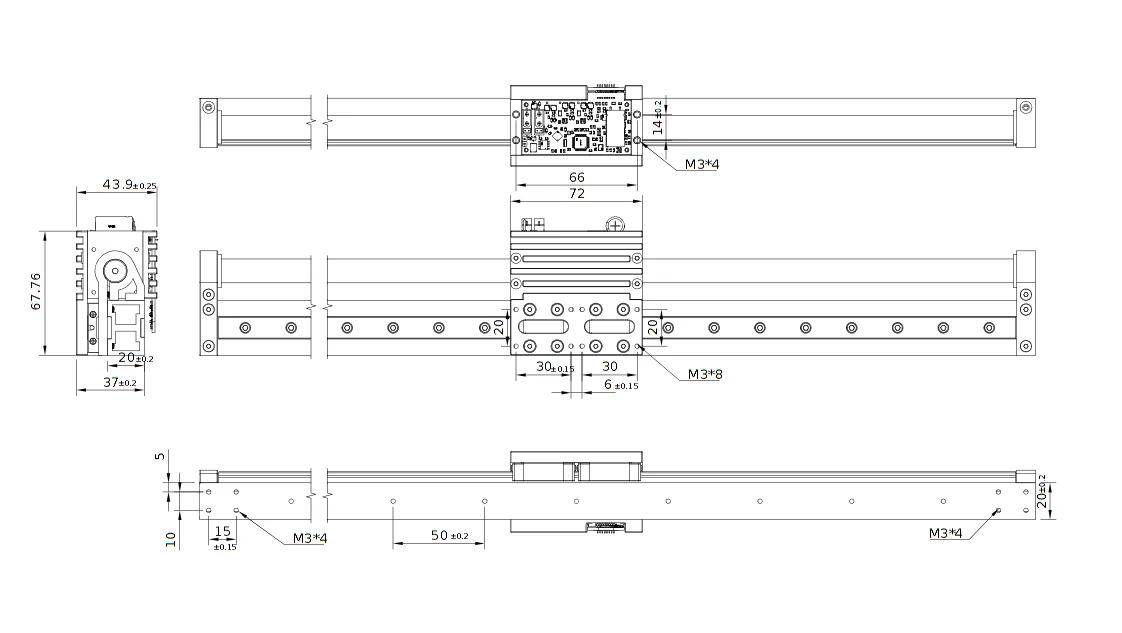
05 Dimensional Drawings
Mounting Dimensions
UNIT: mm
07 Typical Applications
08 Related Products
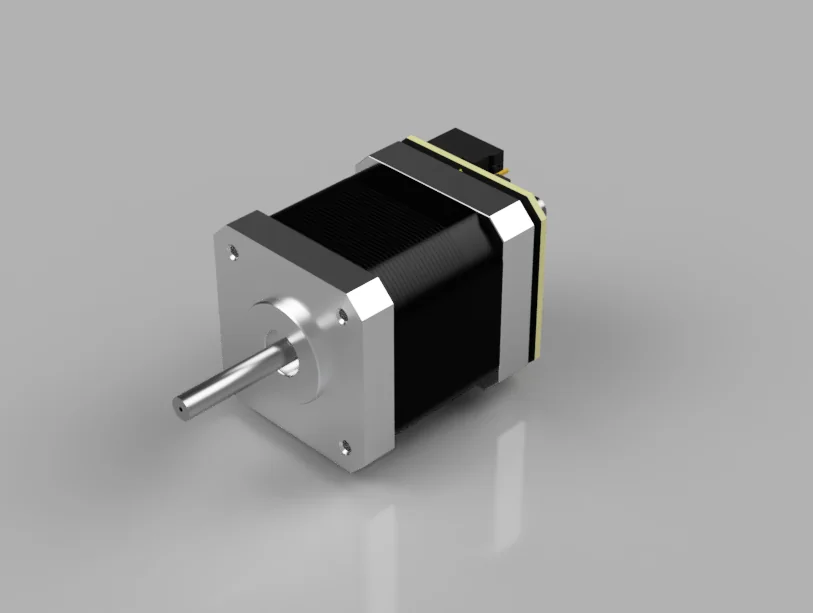
42 Stepper Servo Motor
42 mm flange closed-loop stepper servo · encoder feedback · CANopen CiA402 + Klipper dual-protocol direct drive
- Flange
- 42 mm / NEMA 17
- Holding torque
- 0.6 Nm
- Closed-loop feedback
- 14-bit magnetic encoder
- Protocol
- CANopen · Klipper
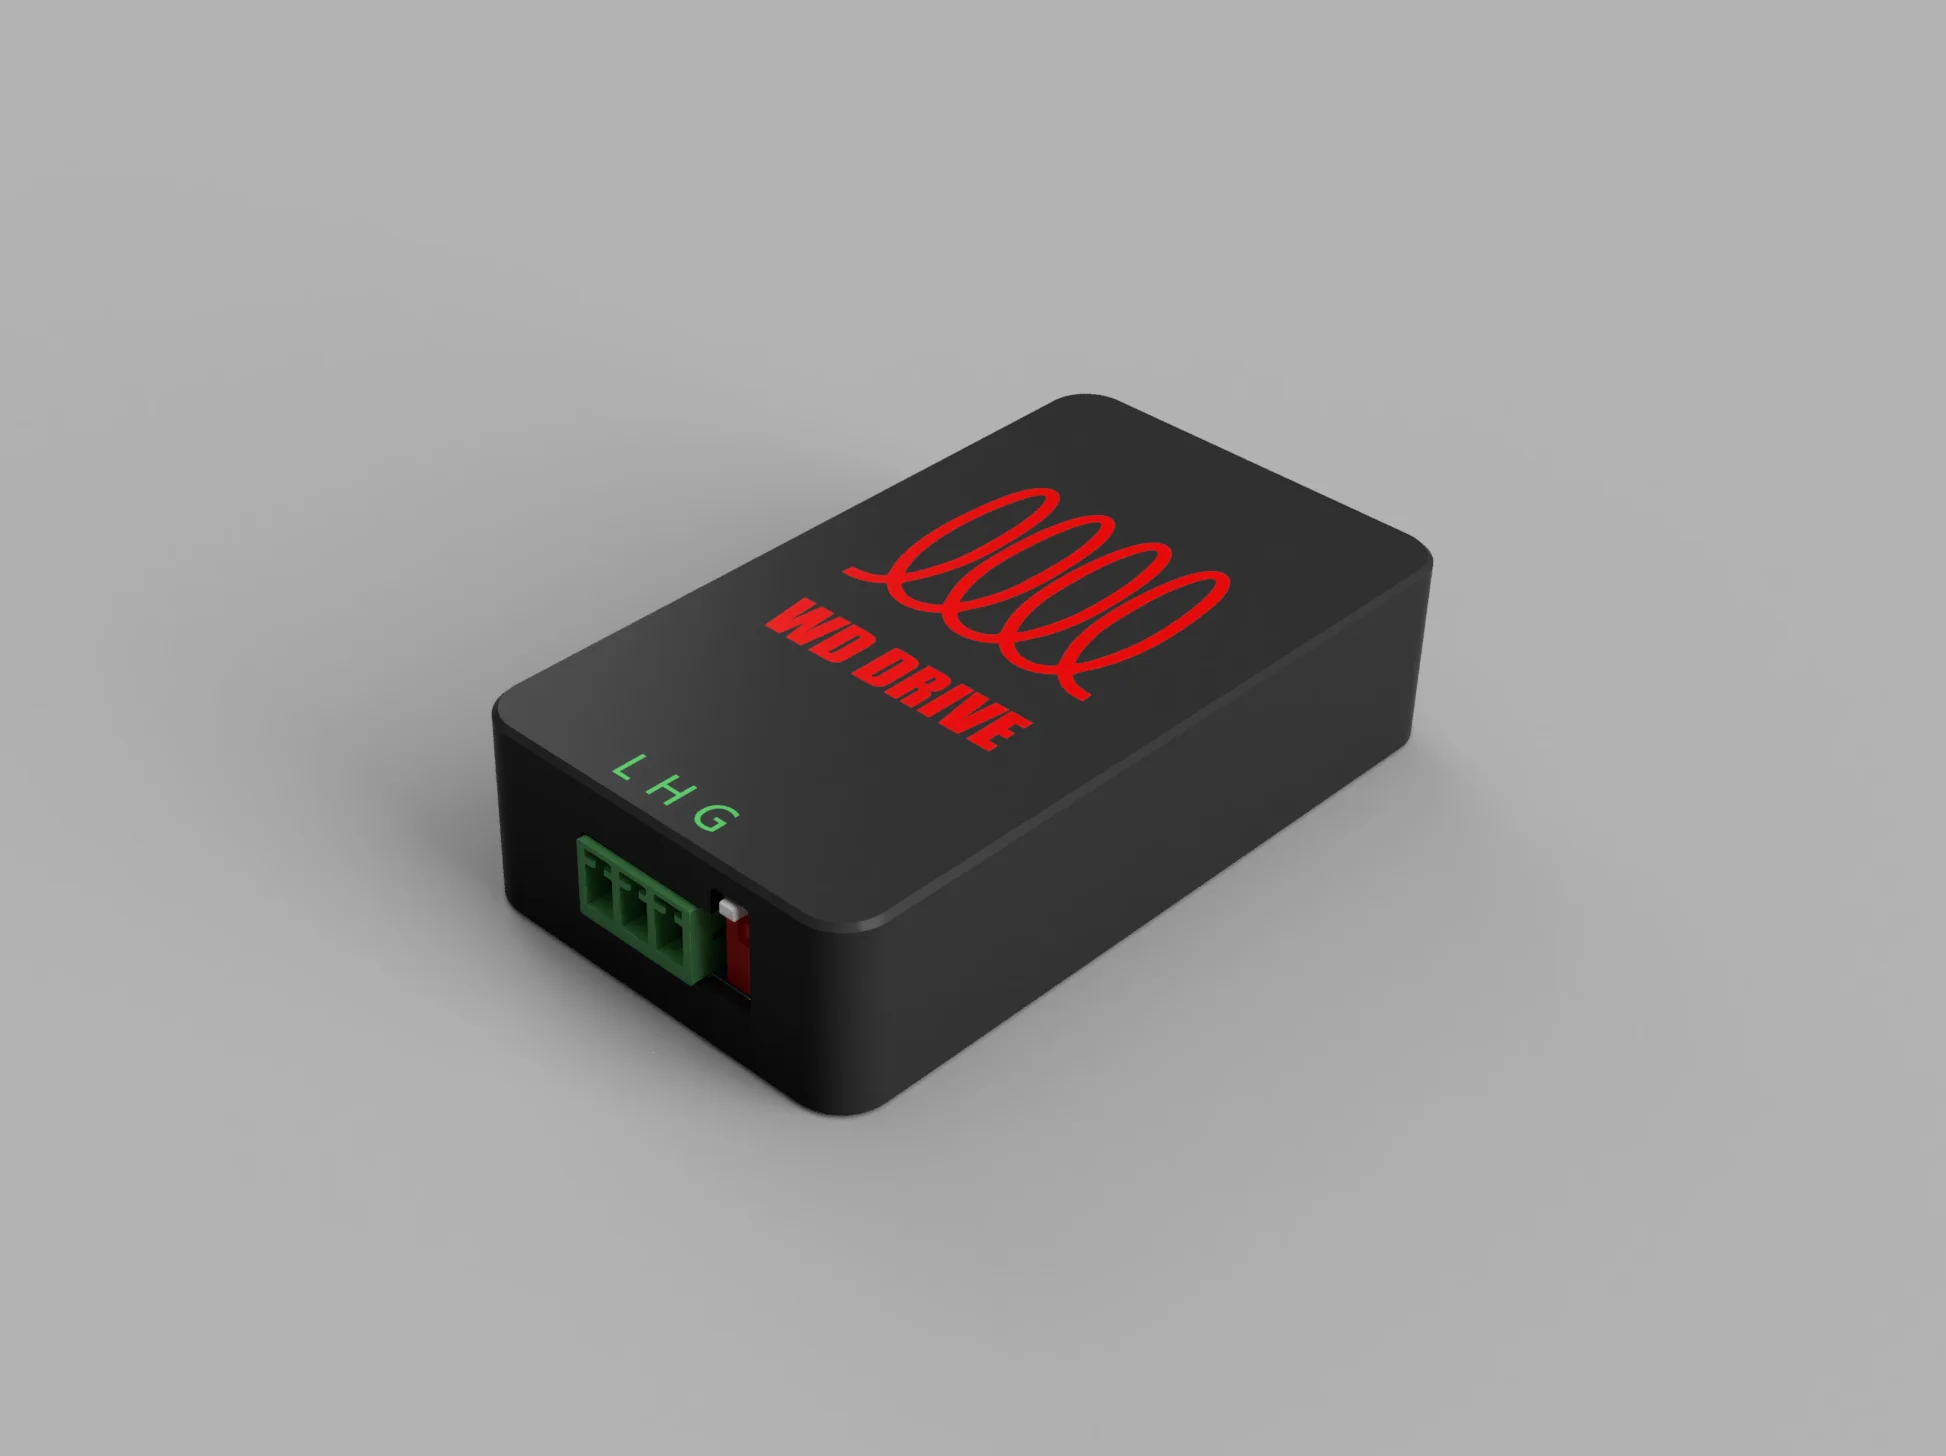
USB-CAN Adapter
Two-in-one: CANopen master | USB-CAN bridge
- Function 1
- CANopen master
- Function 2
- USB-CAN bridge
- Interface
- USB 2.0 + CAN 2.0B
- Baud rate
- 50 kbps … 1 Mbps