USB-CAN Adapters
USB-CAN Adapter
Two-in-one: CANopen master | USB-CAN bridge
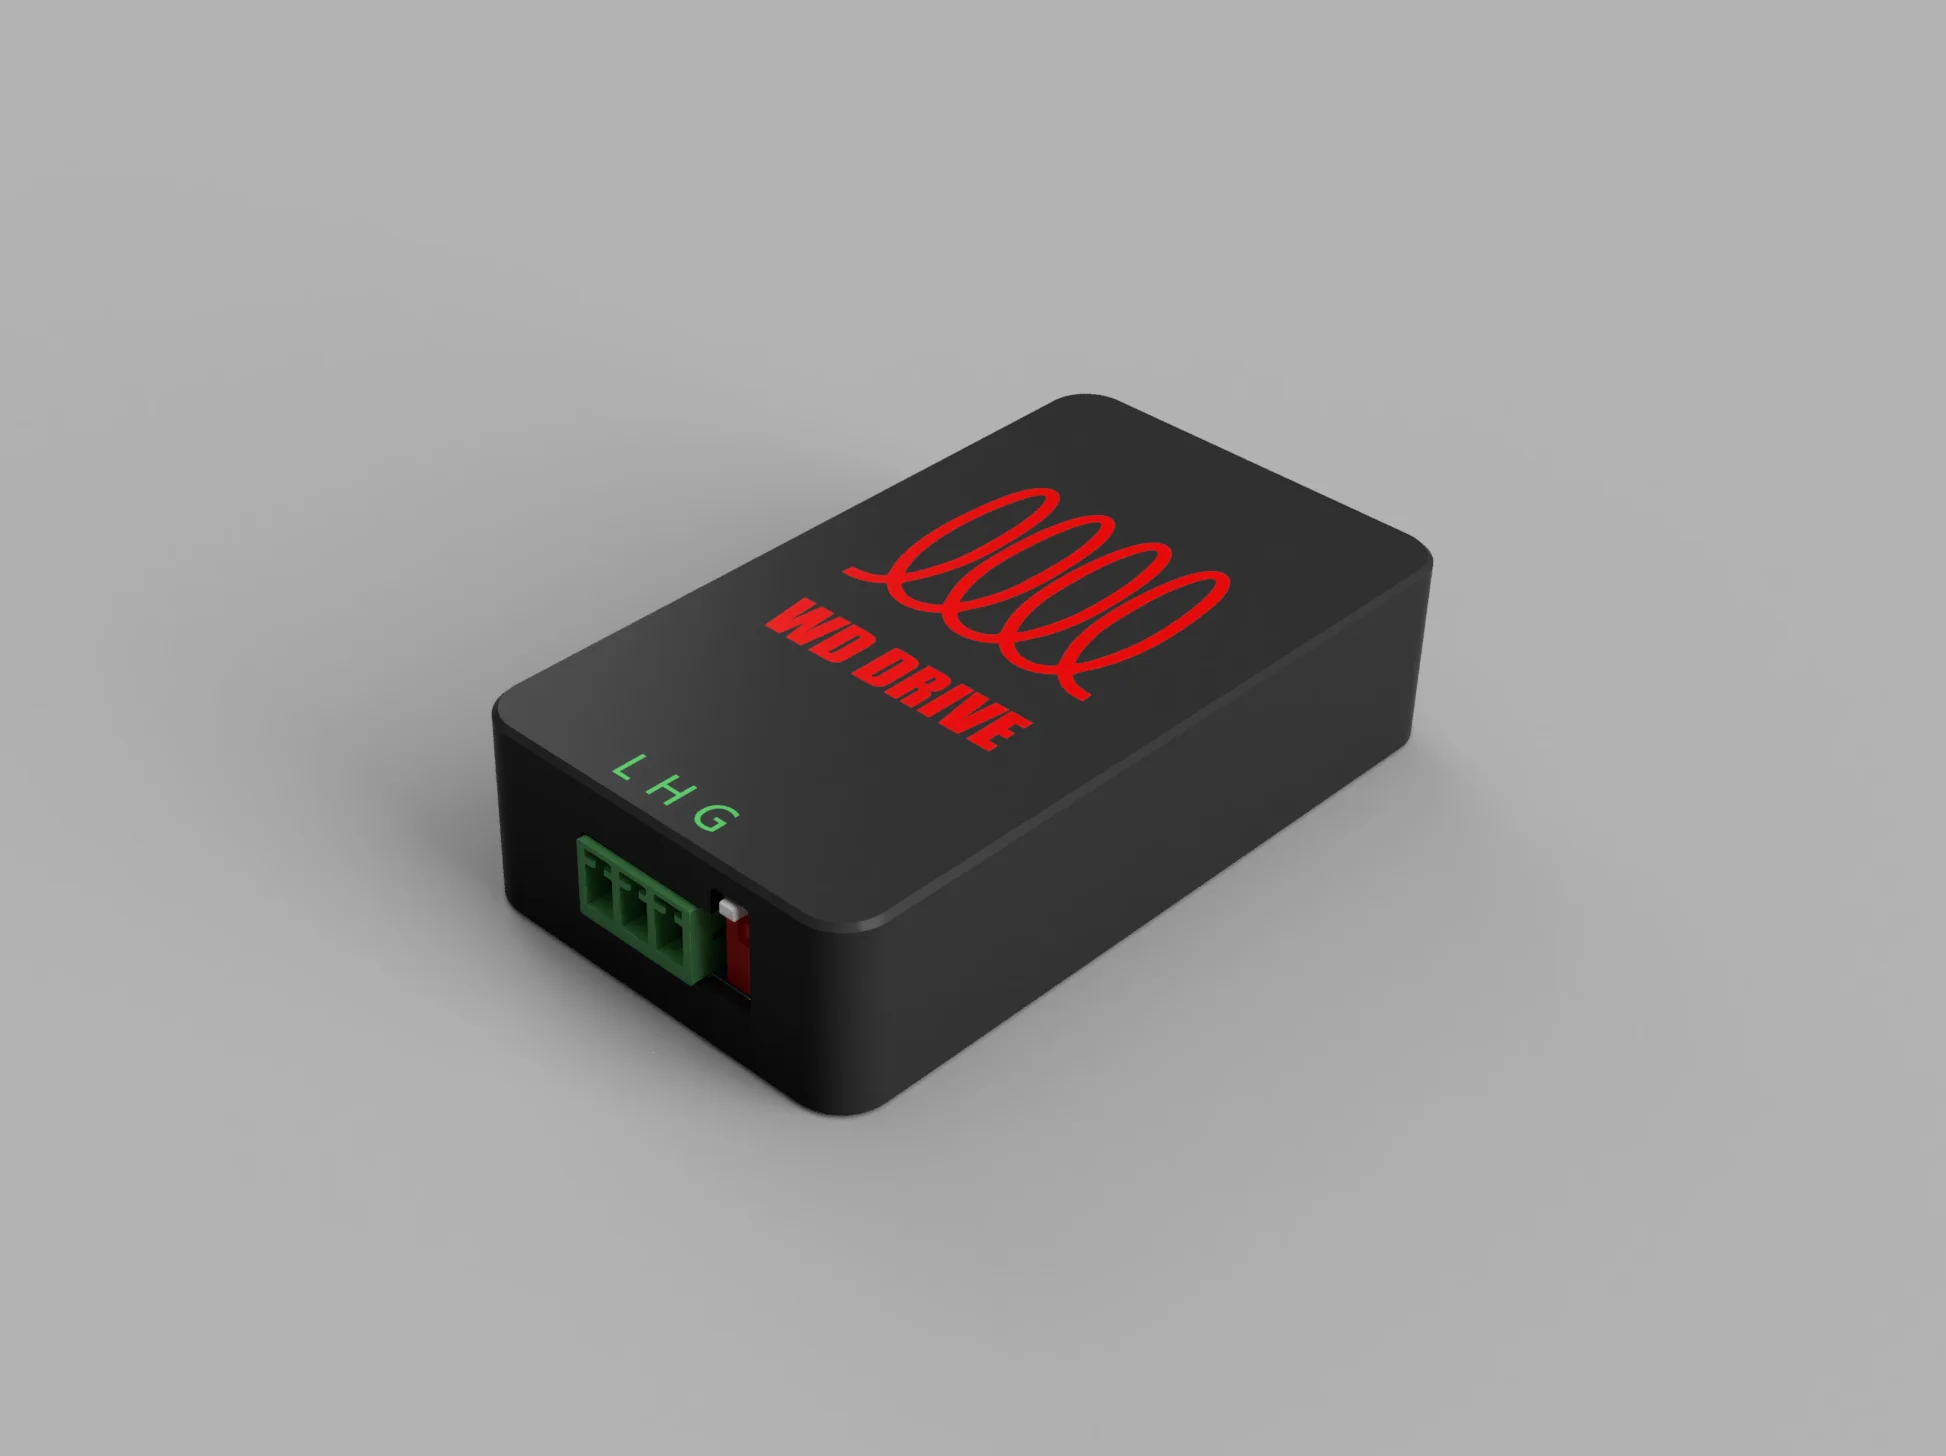
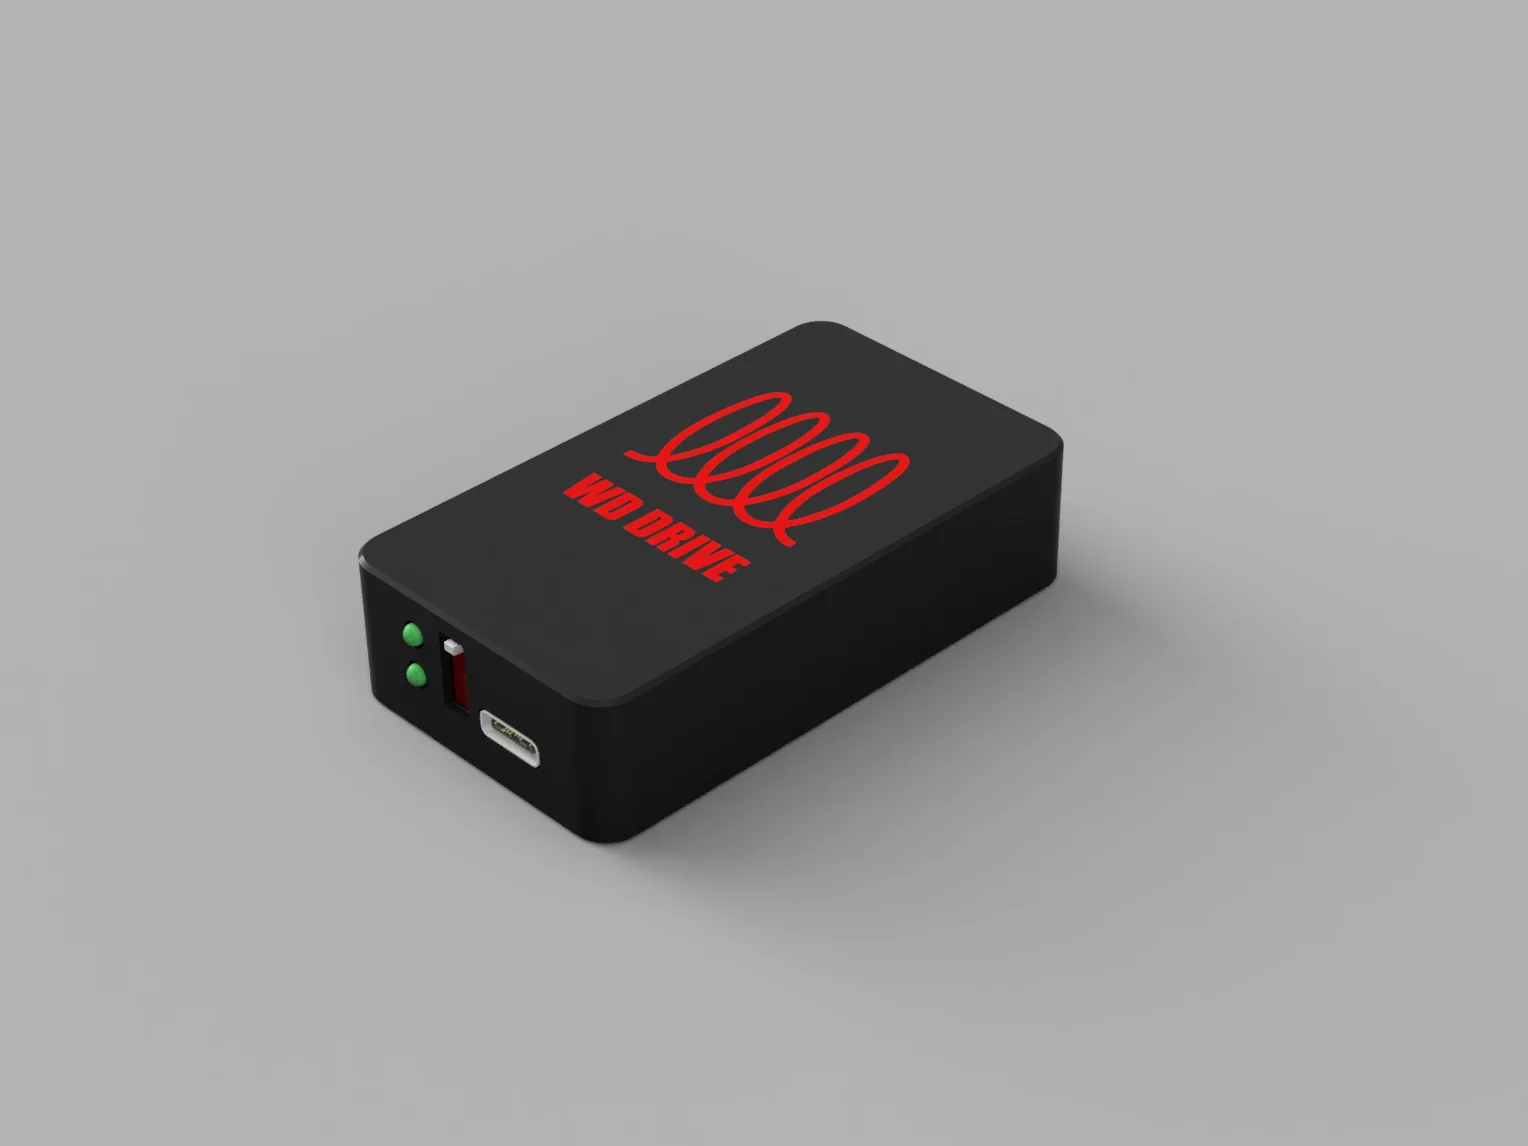
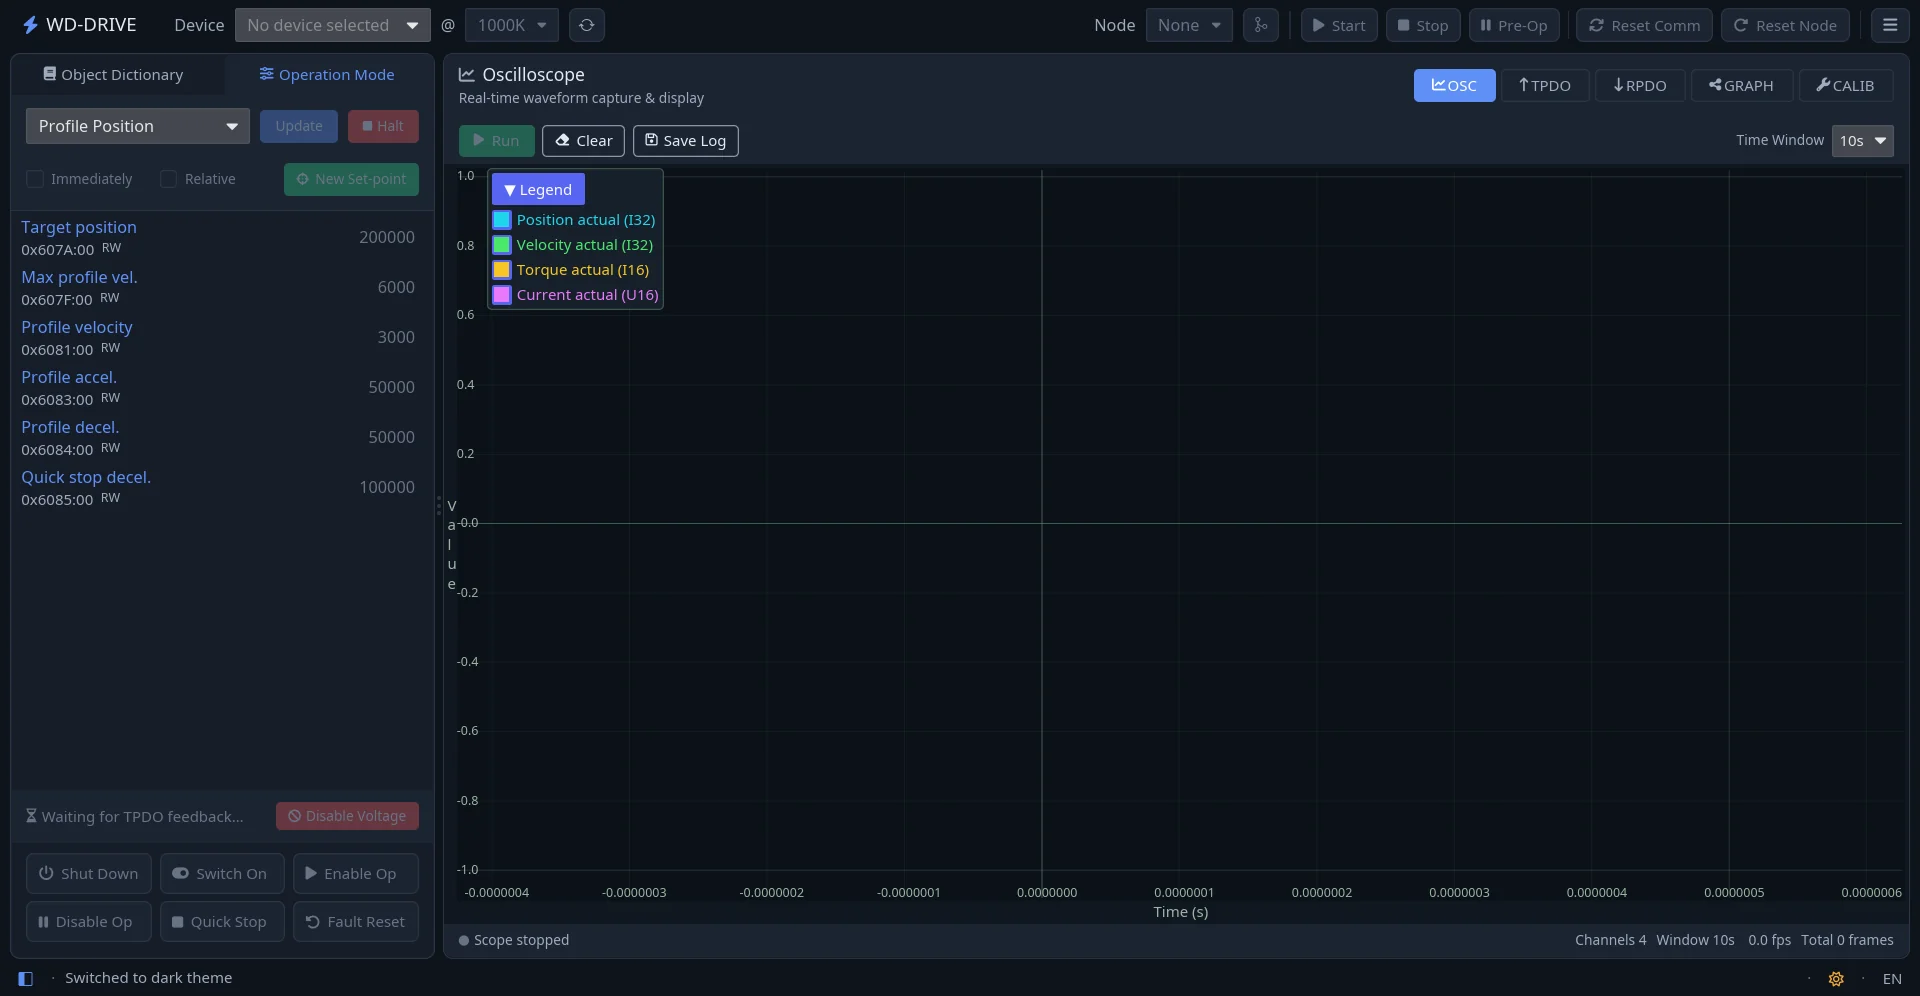
An amphibious USB-CAN adapter. On one side it embeds a CANopen master: with the WD servo debugger host software (Windows / Linux / macOS) you can scan nodes, configure parameters, enable the servo, and control position / velocity / torque of WD servo motors (CiA402). On the other side it works as a general USB-CAN bridge, plug & play on Linux and Windows, and compatible with the open-source CANgaroo software.
- Function 1
- CANopen master
- Function 2
- USB-CAN bridge
- Interface
- USB 2.0 + CAN 2.0B
- Baud rate
- 50 kbps … 1 Mbps
01 Features & Advantages
Why choose USB-CAN Adapter
- 01
CANopen master: full NMT / SDO / PDO / EMCY support
- 02
CiA402 servo control: node scan, parameter configuration, enable, jog and homing
- 03
CANopen master mode: cross-platform servo debug & monitoring in one tool — WD servo debugger
- 04
USB-CAN bridge mode: plug & play on Linux and Windows, works with the CANgaroo open-source software
- 05
Desktop-class: debug WD motors, also works with standard CANopen devices
02 Technical Specifications
USB-CAN Adapter
※ Ratings are typical values at 25 °C ambient temperature; see the datasheet for detailed tolerances.
Functions
| Mode 1 | CANopen master (CiA 301 / 305) |
|---|---|
| Master host software | WD servo debugger (Windows / Linux / macOS) |
| Servo control protocol | CiA 402 · 8 operating modes |
| Mode 2 | USB-CAN bridge |
| Open-source compatibility | SocketCAN / gs_usb / CANgaroo |
Operating Modes · CiA 402
| PP | Profile Position |
|---|---|
| PV | Profile Velocity |
| PT | Profile Torque |
| HM | Homing |
| IP | Interpolated Position |
| CSP | Cyclic Synchronous Position |
| CSV | Cyclic Synchronous Velocity |
| CST | Cyclic Synchronous Torque |
Interface & Electrical
| USB interface | USB 2.0 Type-C |
|---|---|
| CAN interface | CAN 2.0B · KF2EDGR-3.81-3P terminal |
| Baud rate | 50 kbps … 1 Mbps |
| Termination resistor | 120 Ω switchable |
| Power supply | USB 5 V (optional external bus power) |
| LEDs (master mode) | Red = error · Green = active |
| LEDs (bridge mode) | Red = RX · Green = TX |
Environment & Specs
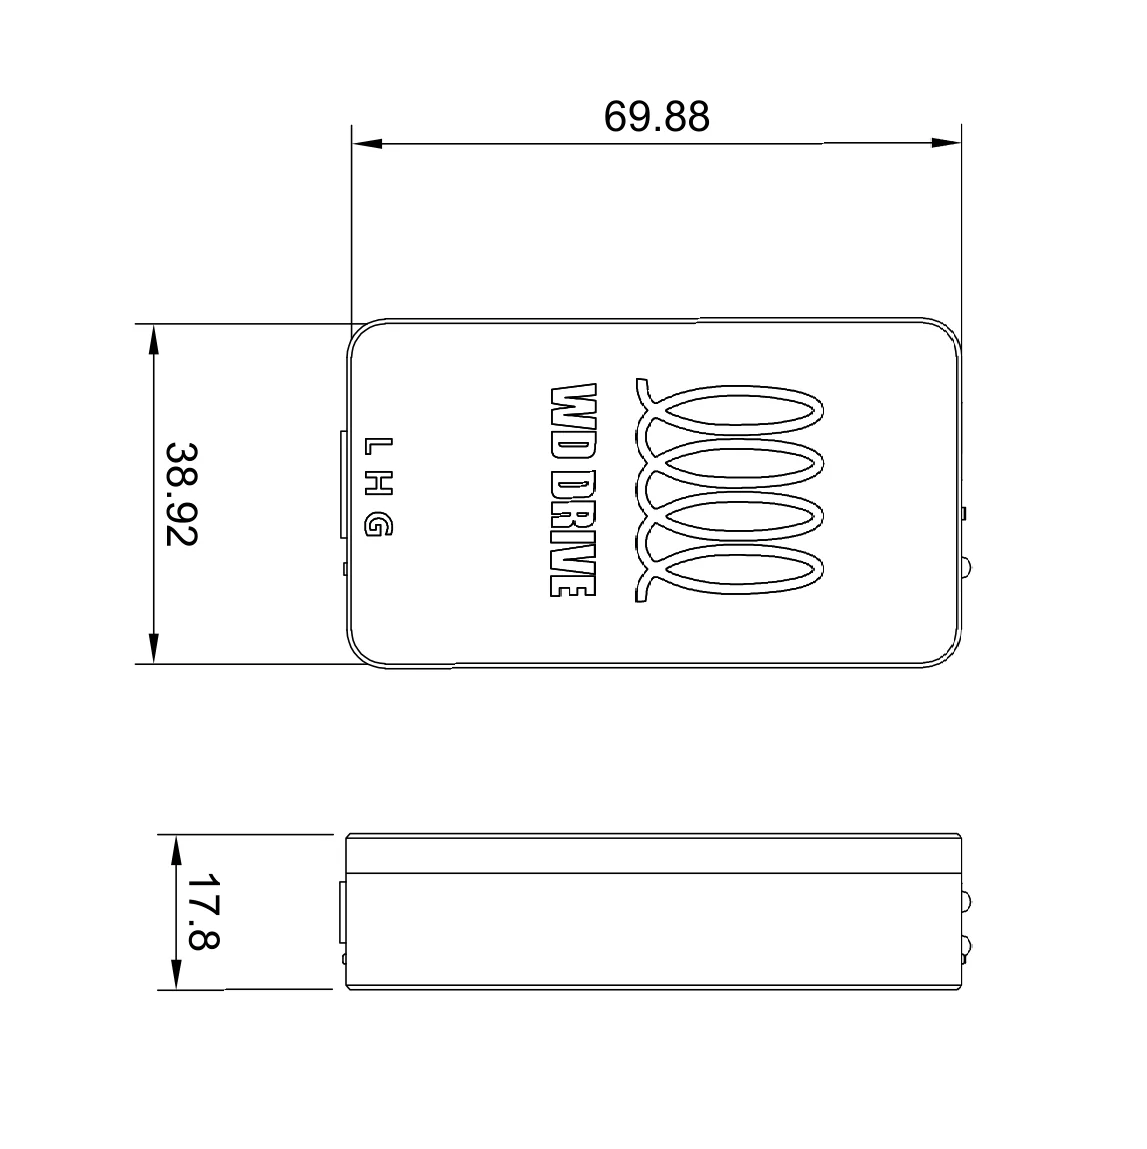
| Dimensions (W×H×D) | 70 × 40 × 18 mm |
|---|---|
| Operating temperature | 0 … +50 °C |
| Supported OS | Windows · Linux · macOS |
| Positioning | Desktop consumer grade |
03 Operating Modes
One device, two ways to use it
Master mode: WD servo debugger, LEDs red=error, green=active; bridge mode: CANgaroo open-source software, LEDs red=RX, green=TX.
05 Dimensional Drawings
Mounting Dimensions
UNIT: mm
07 Typical Applications
08 Related Products
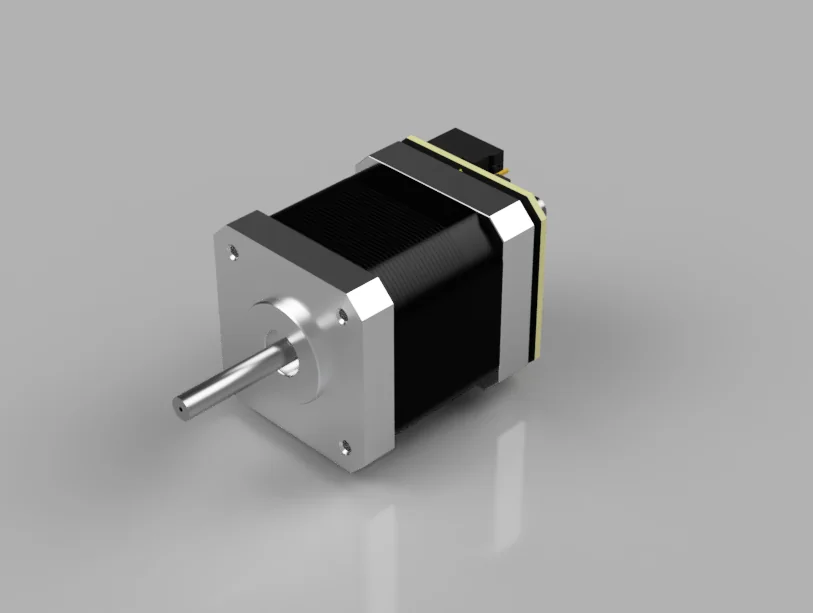
42 Stepper Servo Motor
42 mm flange closed-loop stepper servo · encoder feedback · CANopen CiA402 + Klipper dual-protocol direct drive
- Flange
- 42 mm / NEMA 17
- Holding torque
- 0.6 Nm
- Closed-loop feedback
- 14-bit magnetic encoder
- Protocol
- CANopen · Klipper
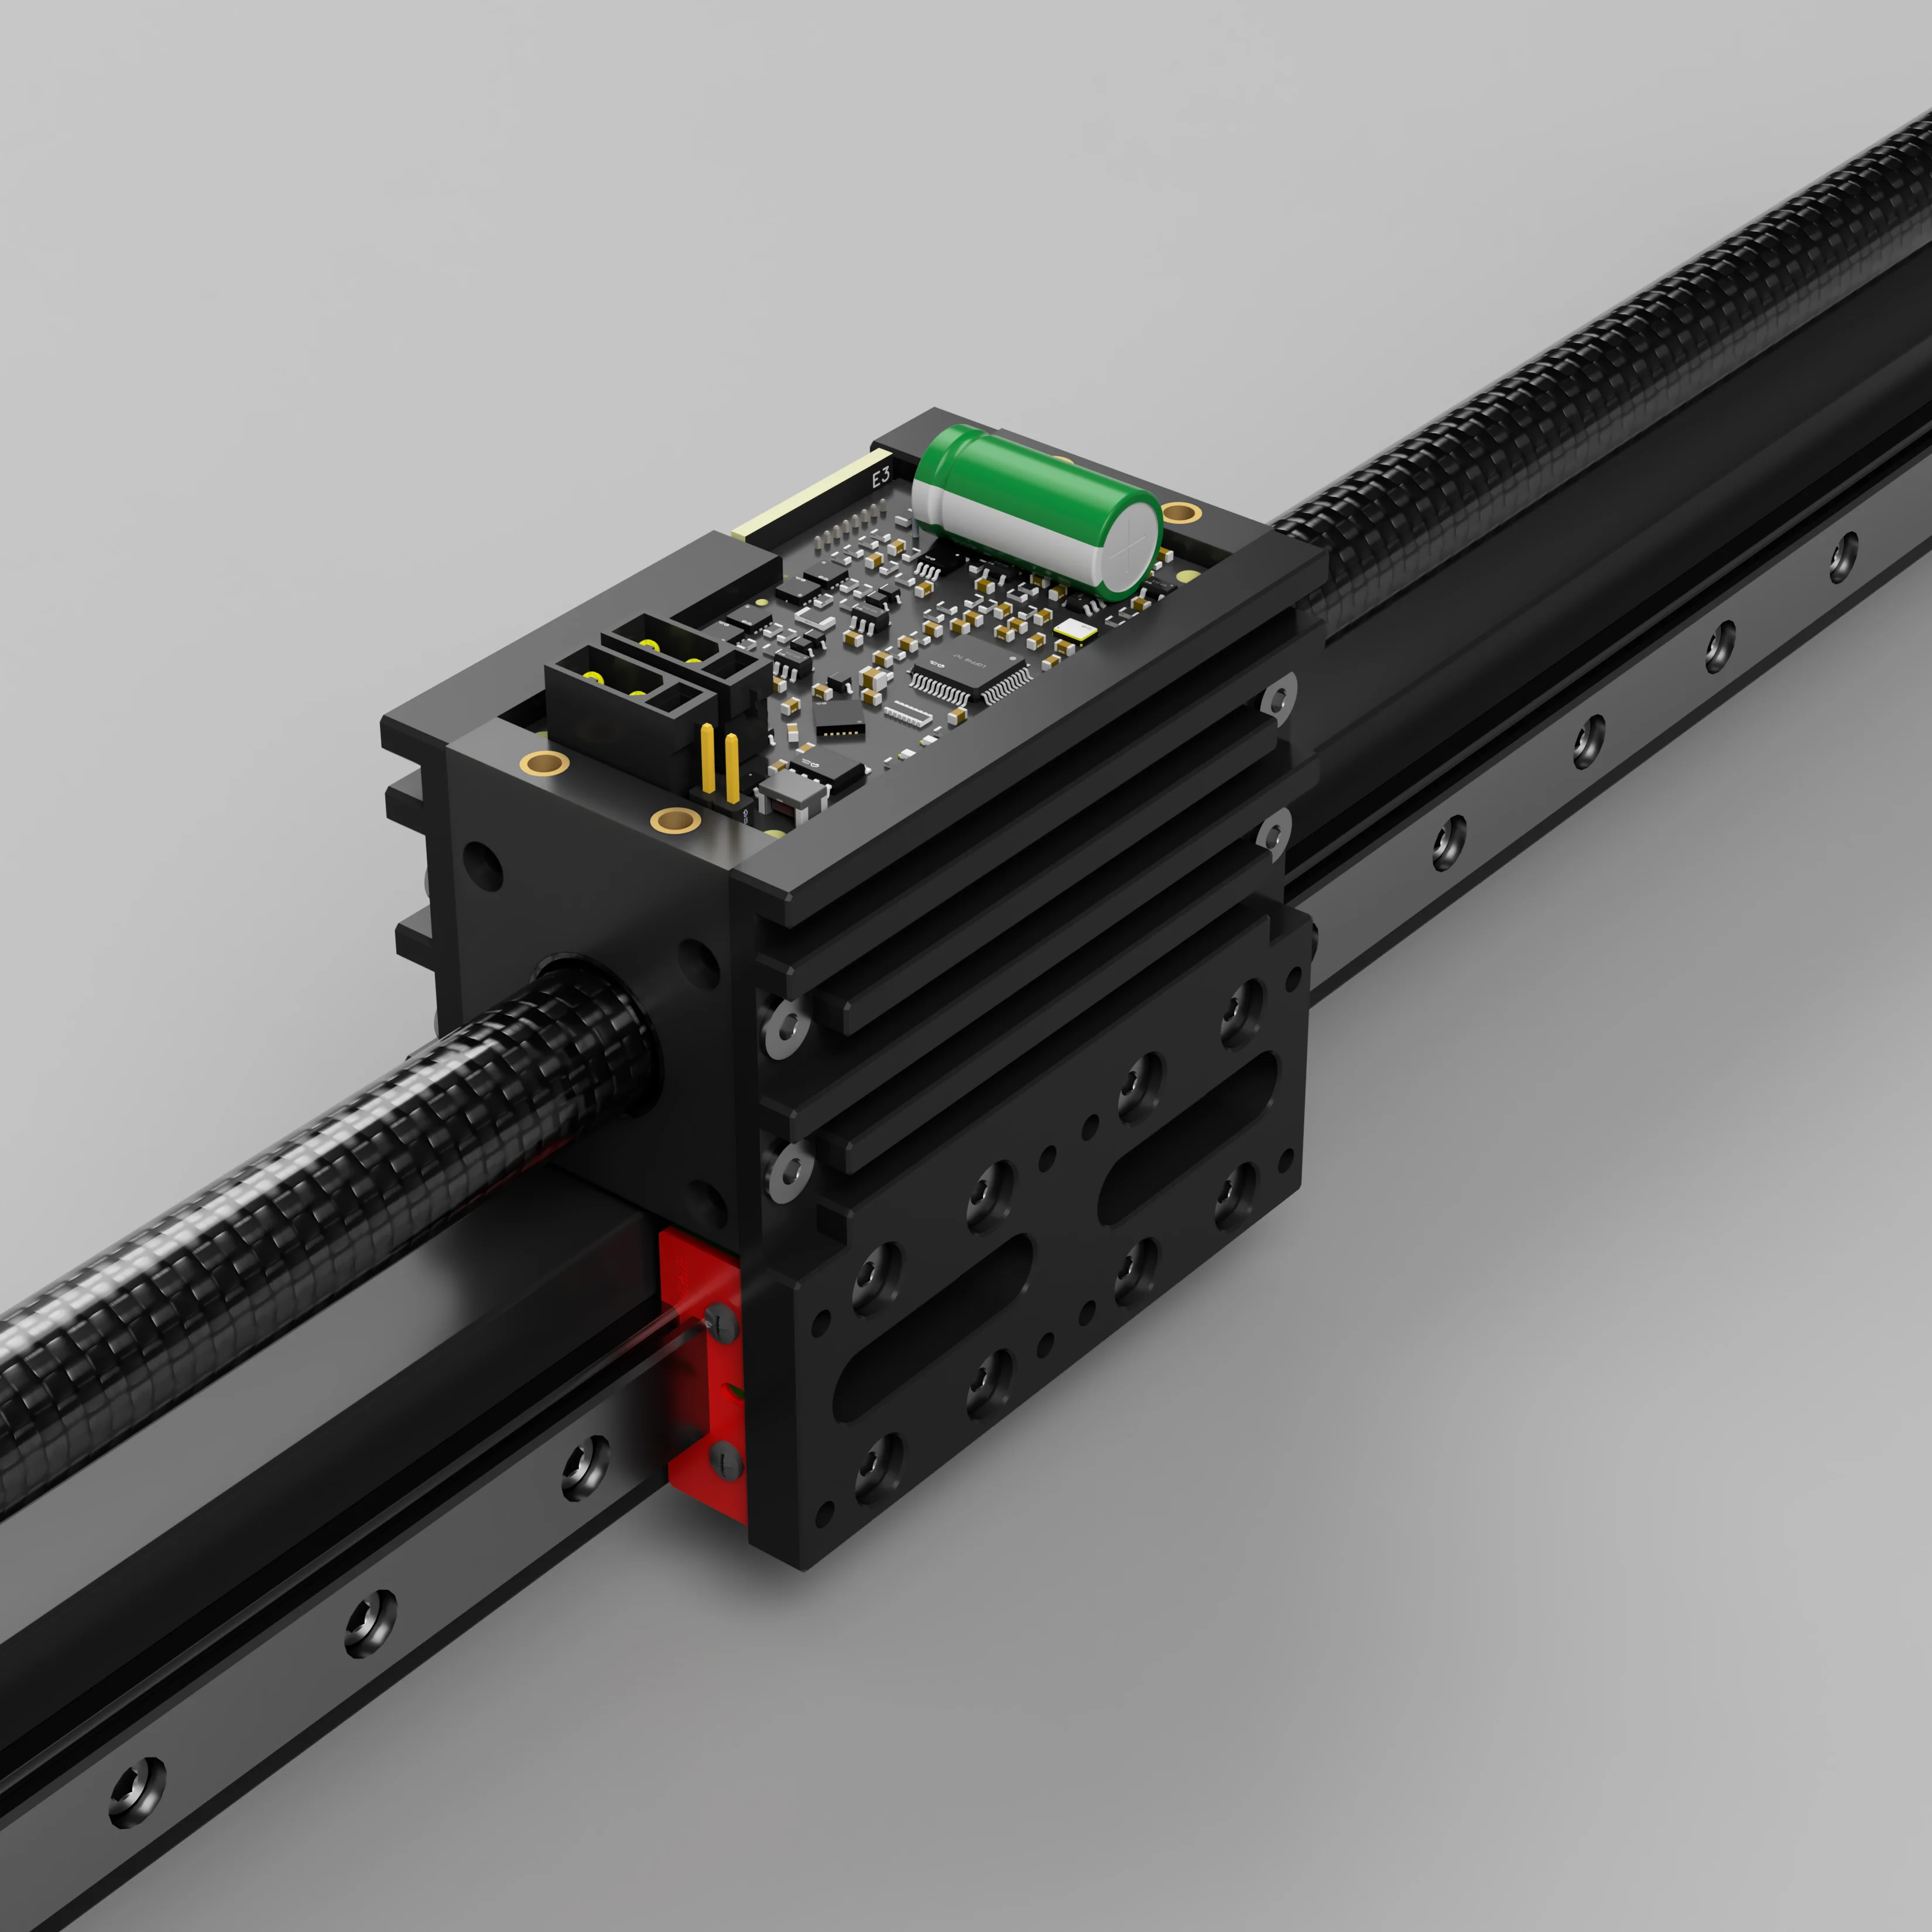
Tubular Linear Motor
Ironless tubular · magnetic-scale closed loop · CANopen CiA402 + Klipper dual-protocol direct drive
- Structure
- Ironless tubular
- Feedback
- Magnetic scale + encoder
- Protocol
- CANopen · Klipper
- Effective travel
- 300 / 400 / 500 / 600 mm